Haptic Avatar
Haptic system for laparoscopic, arthroscopic and thoracoscopic VR training
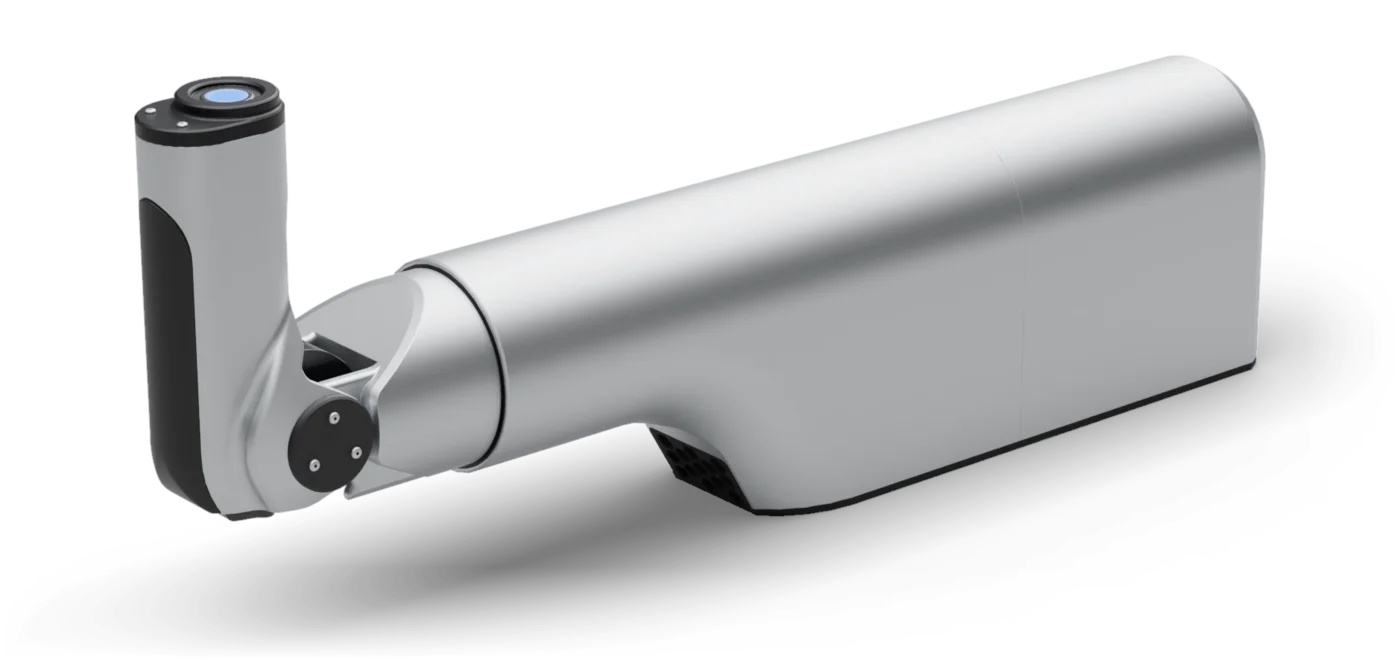
Avatar Port
4DOF haptic device for laparoscopic VR simulation
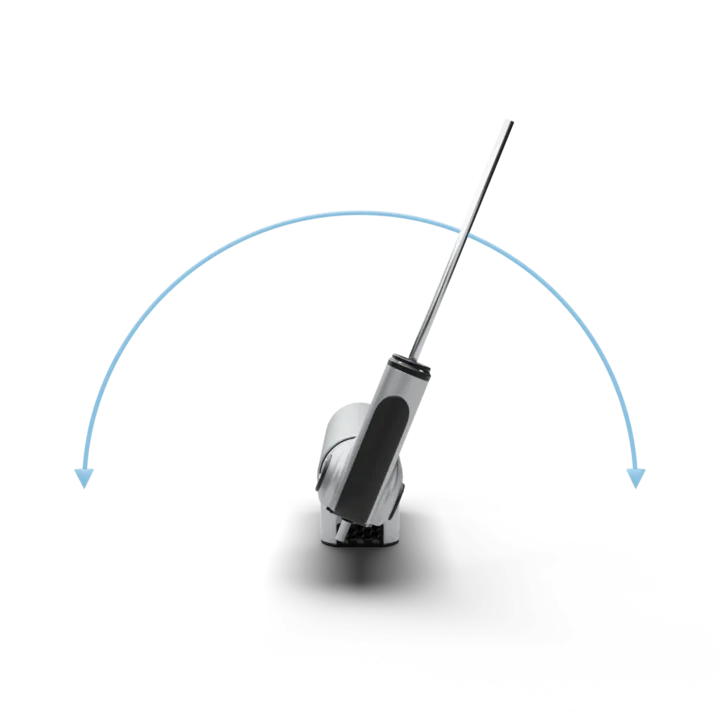
Yaw · Side to side
±90°
Resolution 0.0055°
Peak strength 0.8 Nm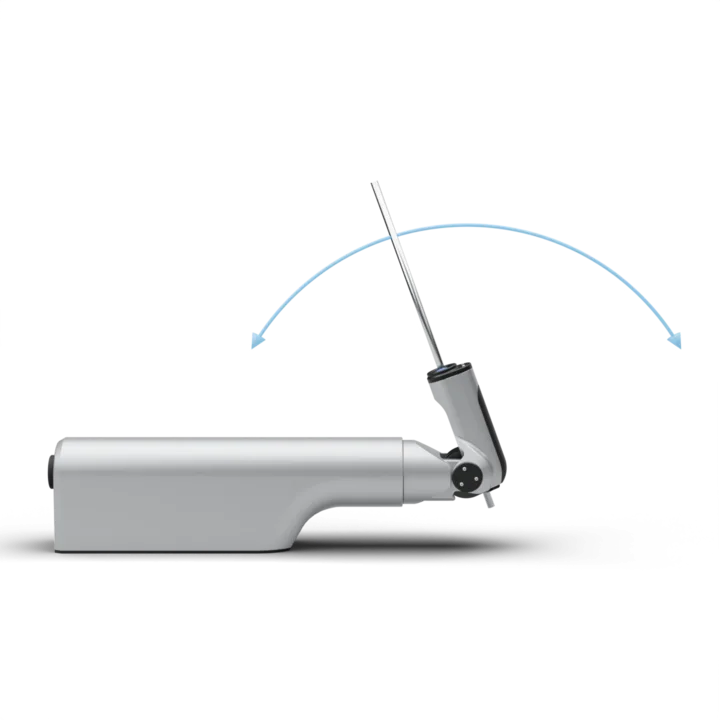
Pitch · Back and forth
±60°
Resolution 0.0055°
Peak strength 1.0 Nm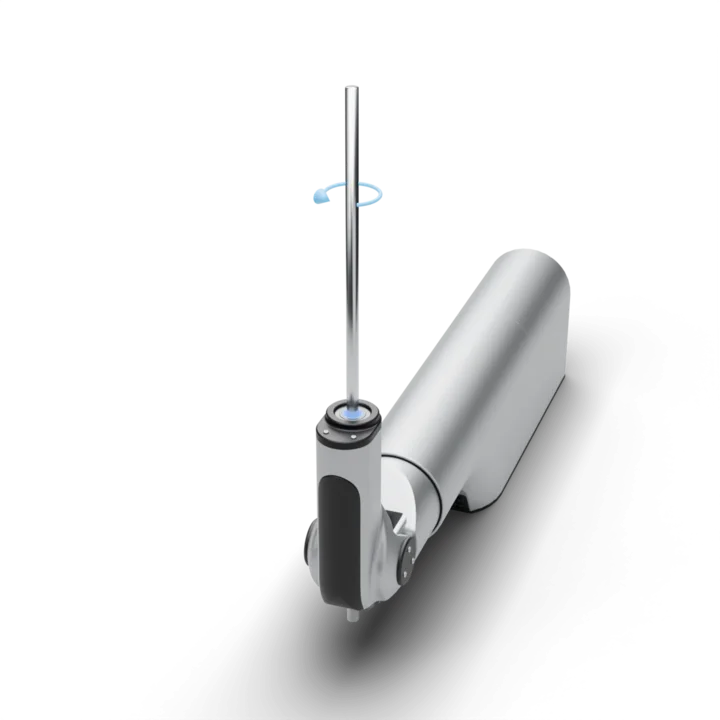
Rotation · Twist
Unlimited
Resolution 0.01°
Peak strength 0.10 Nm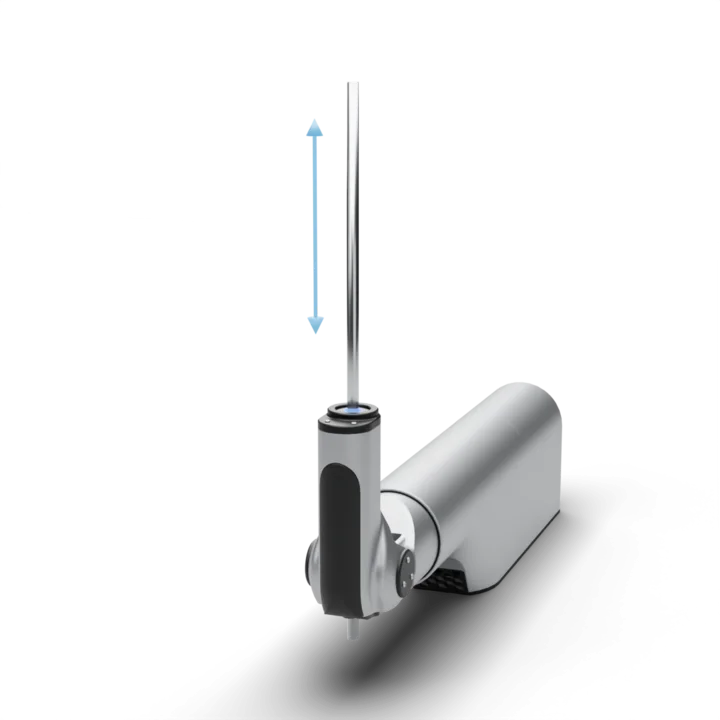
Insertion · In and out
Unlimited
Resolution 5 µm
Peak strength 18 N
Peak strength can be held for a limited time. The Port is over-temperature protected and cooled by an internal fan. With an instrument inserted 100 mm, the sideways position resolution at its tip is roughly 20 µm.
Features
- Retractable and insertable instruments.
- Detection and identification of instruments.
- Integrated power, amplifiers, motor control, cooling and haptics computer.
- Modular mounting system for simple setup and customization.
- The insertion part is lit for didactic purposes, auto or user controlled.
Specifications
| Applications | Laparoscopy, arthroscopy, thoracoscopy | Virtual reality simulation training. |
|---|---|---|
| Communication | USB (Micro-B to A) | To a USB 3.0 hub or directly to the computer. Current requirement 0.9 A. |
| Force loop | >6 kHz external | Through the simulation. |
| Power | Internal Li-Ion battery | Four 3.7 V cells, 37 Wh in total, charged via USB. An external 16.8 V charger (provided) charges four times faster. |
| Calibration | Automatic zero angle | Yaw and pitch. The Port blinks fast when it needs calibration; move it in a small circle around the zero position. |
| Minimum distance | 50 mm | Between Ports, without mechanical interference. |
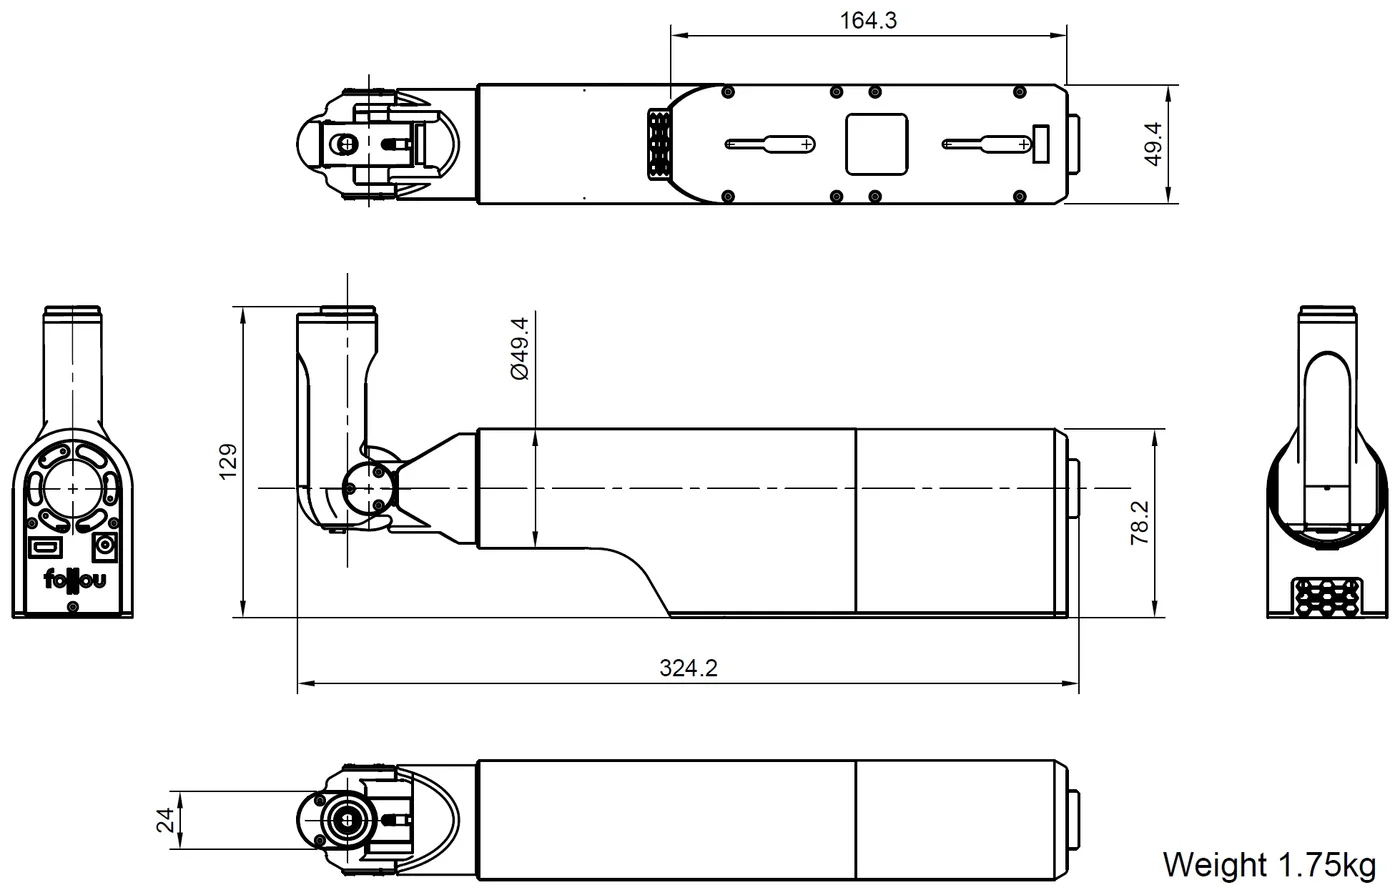
| Weight | 1.75 kg |
Dimensions
Avatar Instruments
Instrument handles, shafts and scope
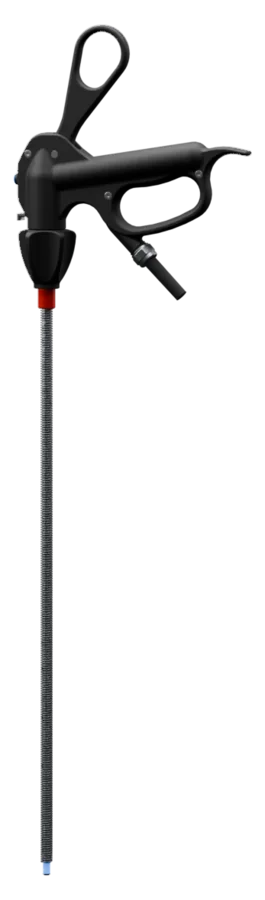
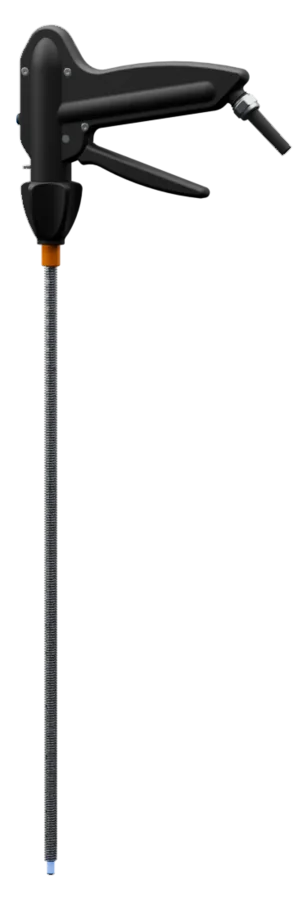
Grasper
Force feedback
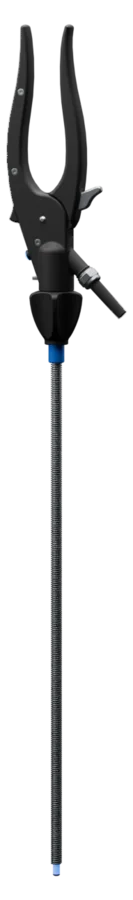
Clip Applier
Force feedback
Needle Driver
Sensing

Straight Tool
Sensing
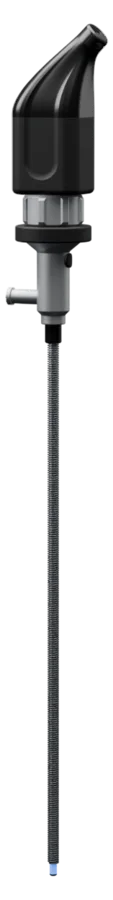
Scope
Sensing
The shaft

- Identification tip
- Thread and two grooves
- Colour marker
- Quick connector
Standard 310 mm for laparoscopy and thoracoscopy, 210 mm for arthroscopy. Any length from 200 mm to 450 mm at purchase.
Standard set
- Red
- Orange
- Yellow
- Green
- Blue
- Purple
- Black
Extended set
- Brown Additional scope
- Grey Special instrument 1
- White Special instrument 2
Mate a handle with a shaft and connect it to the IBox connector of the same colour. Handles with force feedback need red, orange, yellow or green. The black shaft is for the Scope.
Handle and Scope performance
| Handle grip (force feedback) | 0–100 %, typically 30° | Resolution 0.1 %, 0.01°, peak strength 10 N |
|---|---|---|
| Scope camera angle | 0–360°, unlimited turns | Resolution <0.1° |
| Scope zoom knob | 0–360°, unlimited turns | Resolution 32 ticks per turn |
Special instruments
Because of the Avatar's unique system with a Port that accepts a simple threaded/grooved instrument shaft, and instruments that are individually sensed/detected, adaptation to special instruments is straightforward.
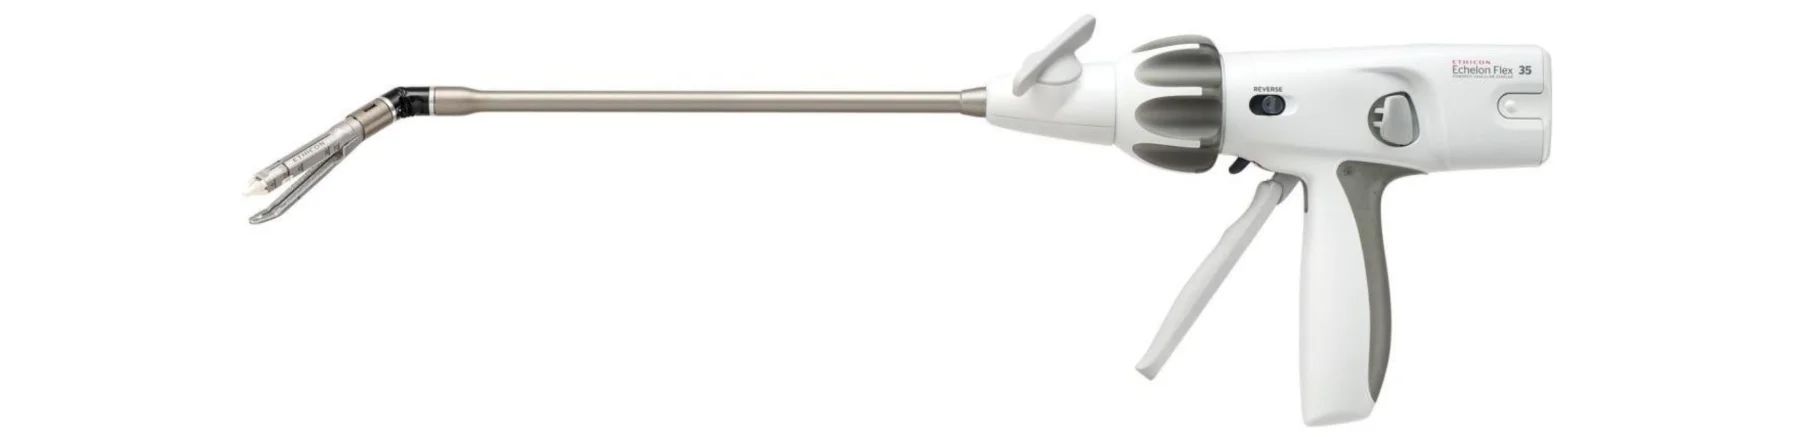
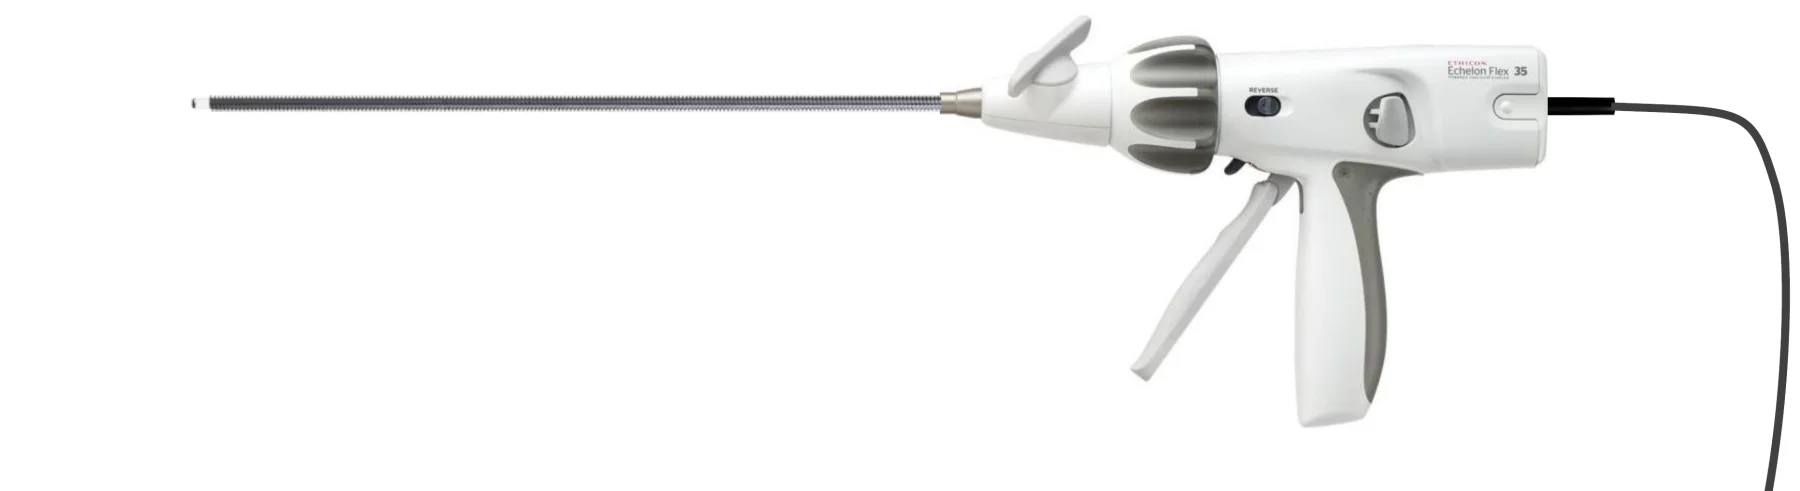
- Identity tip with index 9, unique for the Echelon
- Stainless steel shaft, 31 cm long (as the original shaft)
- USB cable
The example shows an Echelon Flex 35 (ETHICON) which is equipped with sensors to interact with the Avatar System. Other examples are ETHICON Echelon Flex 3000, Covidien Signia staplers, Medtronic Endostitch.
Depending on the number and type of sensors needed, the instrument handle is either USB-connected, or connected to the IBox.
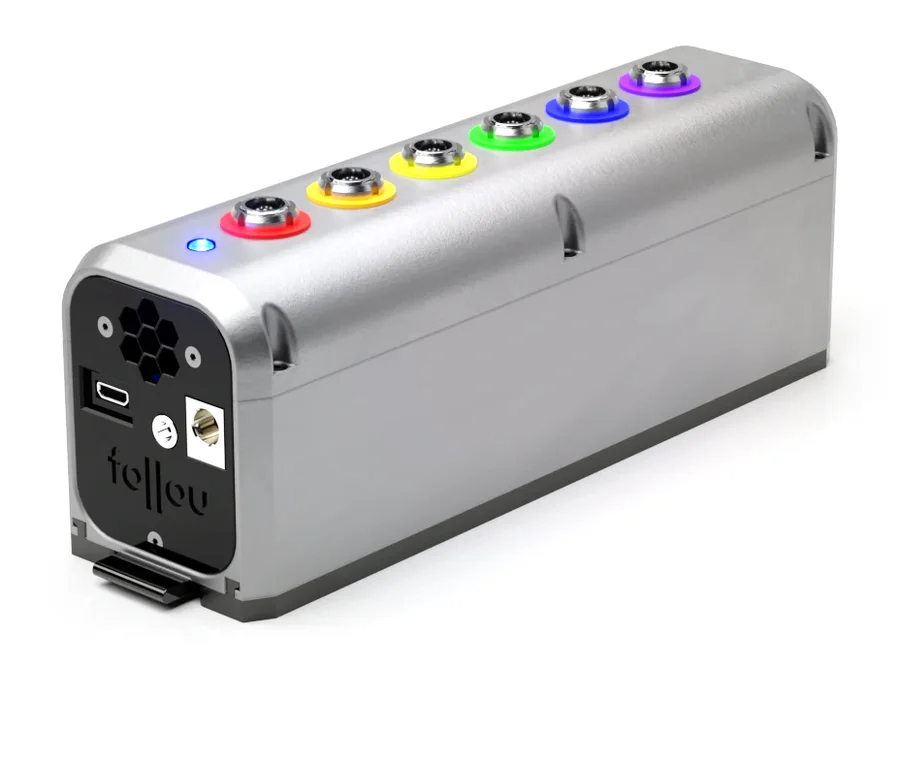
IBox
Reads the handles and drives their force feedback.
- Channels
- 6, of which 4 with force feedback
- Connection
- USB; USB-charged, with an internal Li-Ion battery for the motors
- Size
- 180 × 49.4 × 57 mm (L × W × H)
- Weight
- 800 g
- Pedal
- A Double Footswitch Pedal connects to a 3.5 mm audio jack.
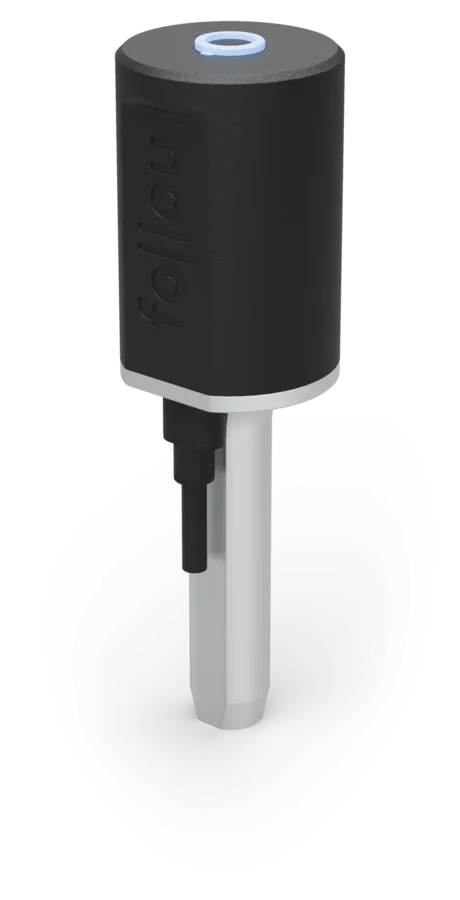
Avatar Trocar
4DOF tracking device for laparoscopic VR simulation
0.0055°
Yaw and pitch resolution
3.6µm
Insertion resolution
~35mm
Minimum distance between Trocars
100g
Weight
- Can also track Ø3–5 mm real laparoscopic instruments, though not their handle opening.
- Insert in any silicone manikin or use with an Avatar Trocar Gimbal.
- Detects and identifies Avatar Instruments, like the Avatar Port.
Structures
Mount the Ports in your preferred way.
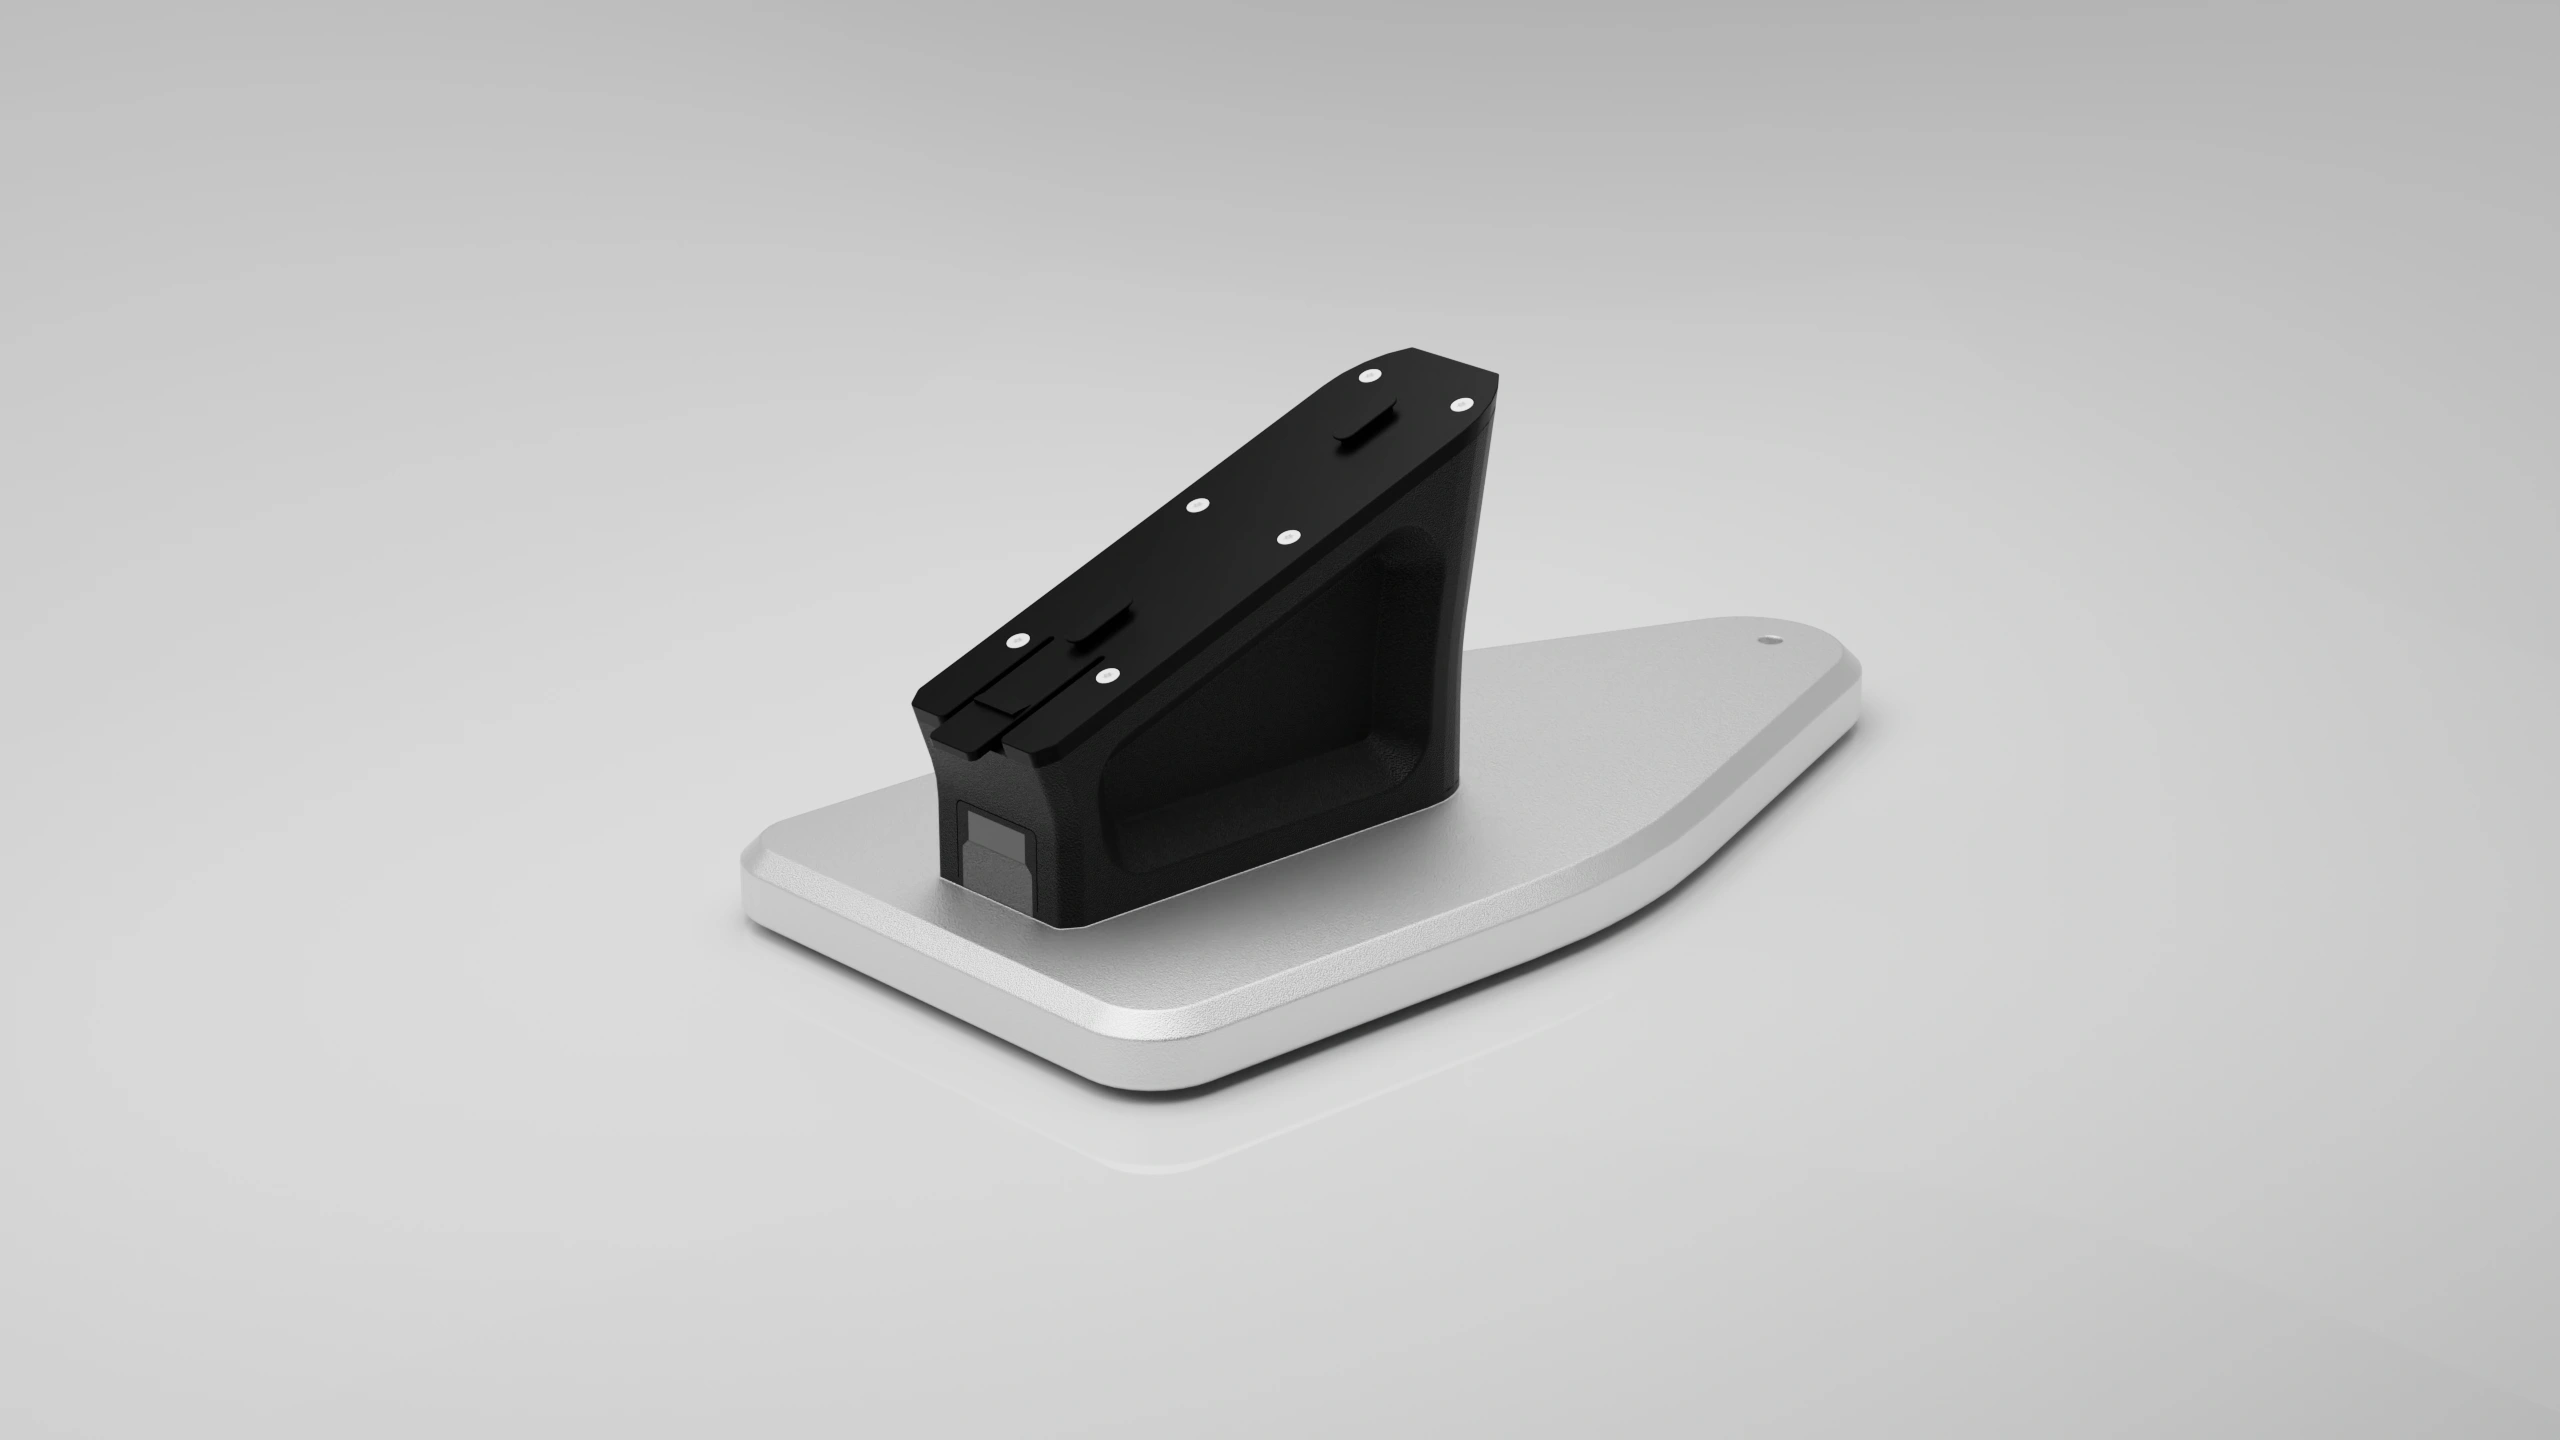
Fixed ramp on plate

Movable ramp on rail

Fixed workstation

Tool stand
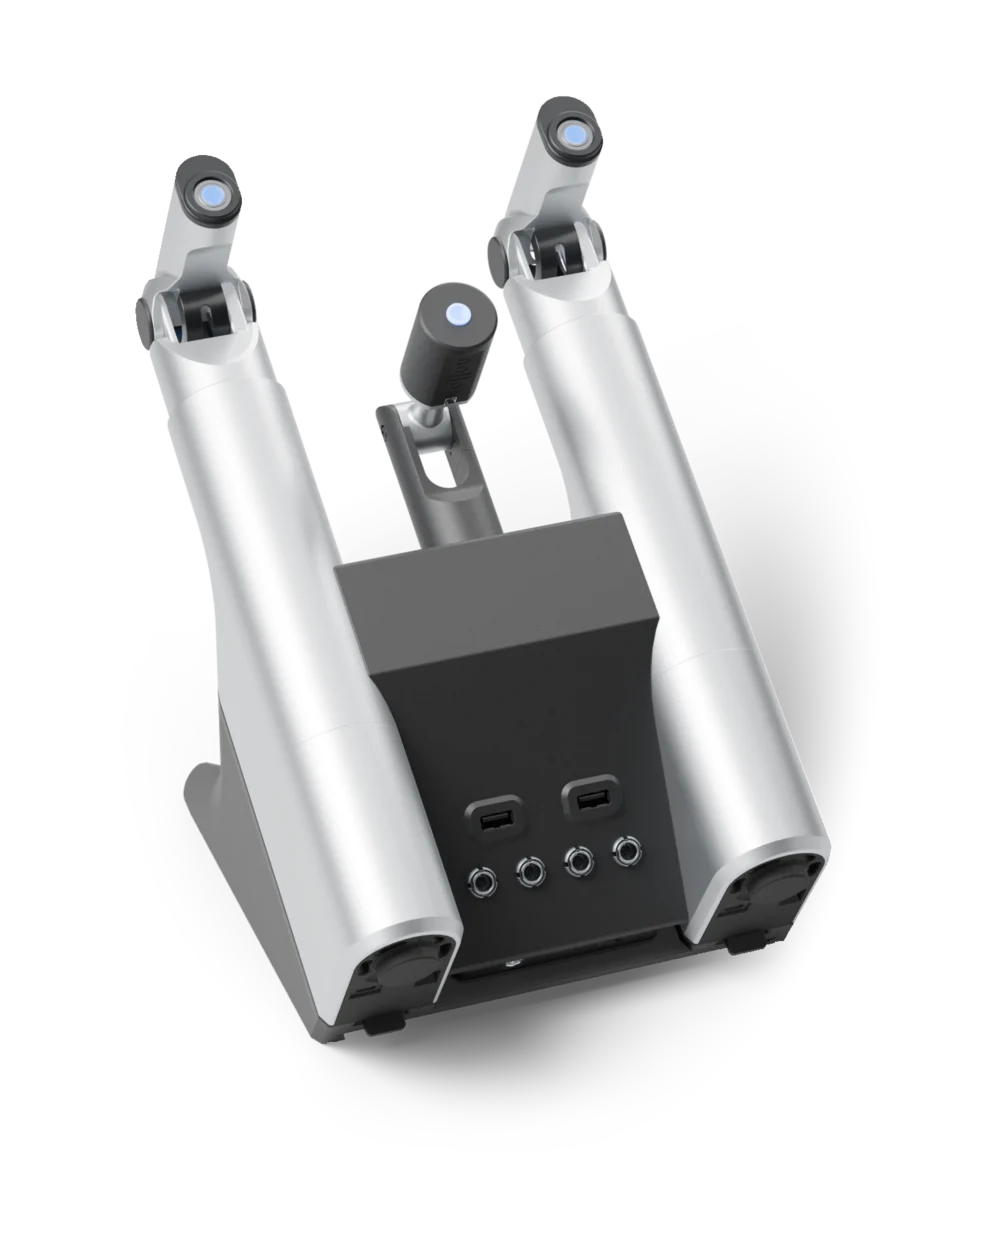
Transportable Tri‑port
Integration
Follou's device library connects Haptic Avatar to your simulation, whatever language it is written in.
Your simulation
Python, C++, C#, Unity or any other environment
From Follou
Follou device library
A DLL on Windows, dylib on macOS, .so on Linux
Haptic Avatar
Ports, Trocars, IBox and Scope. One USB cable per device.
The library finds and identifies every connected Follou device. Your simulation reads positions and orientations and sets forces, at up to 7000 Hz for several devices (1000 Hz for the Trocar) and about 35 µs per update. For Unity, a ready-made prefab connects the devices automatically.
Parts and accessories
Devices

Avatar Port
HA-HD-001
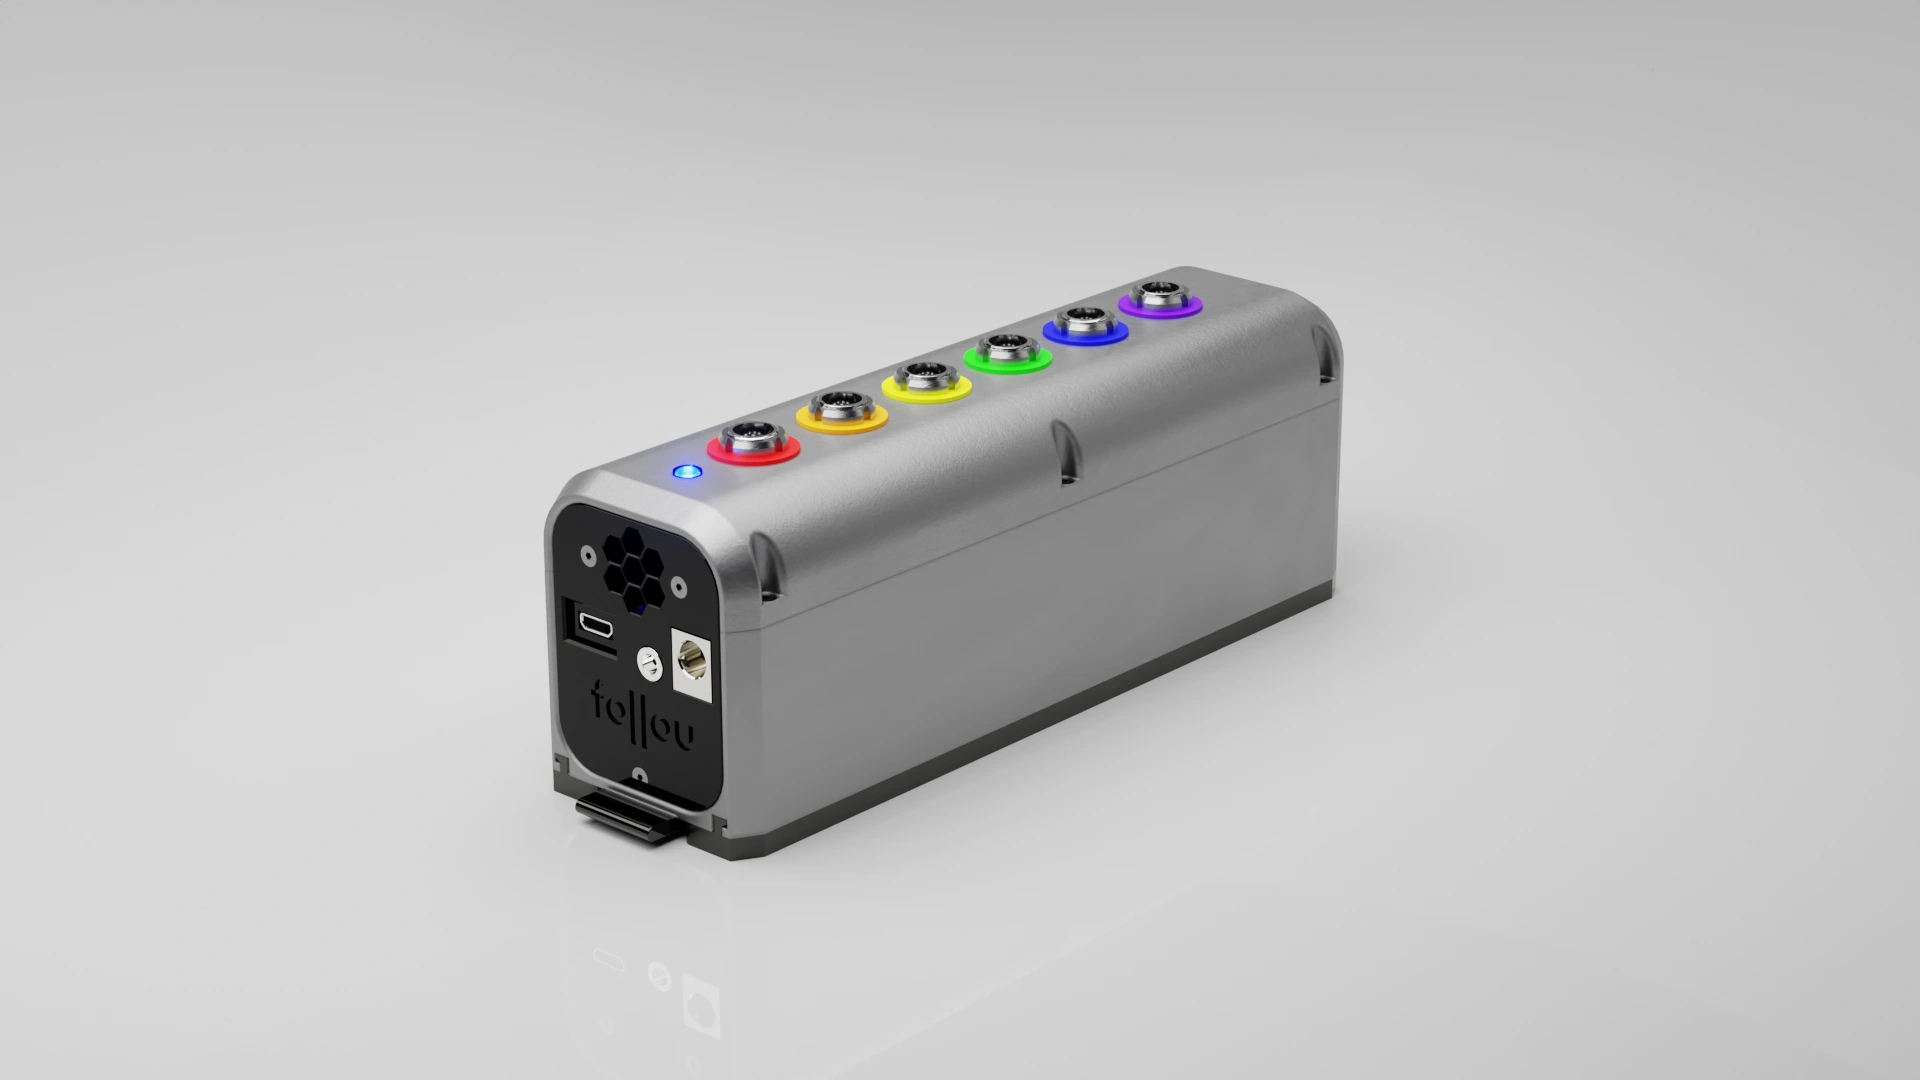
IBox
HA-IB-001
Instruments
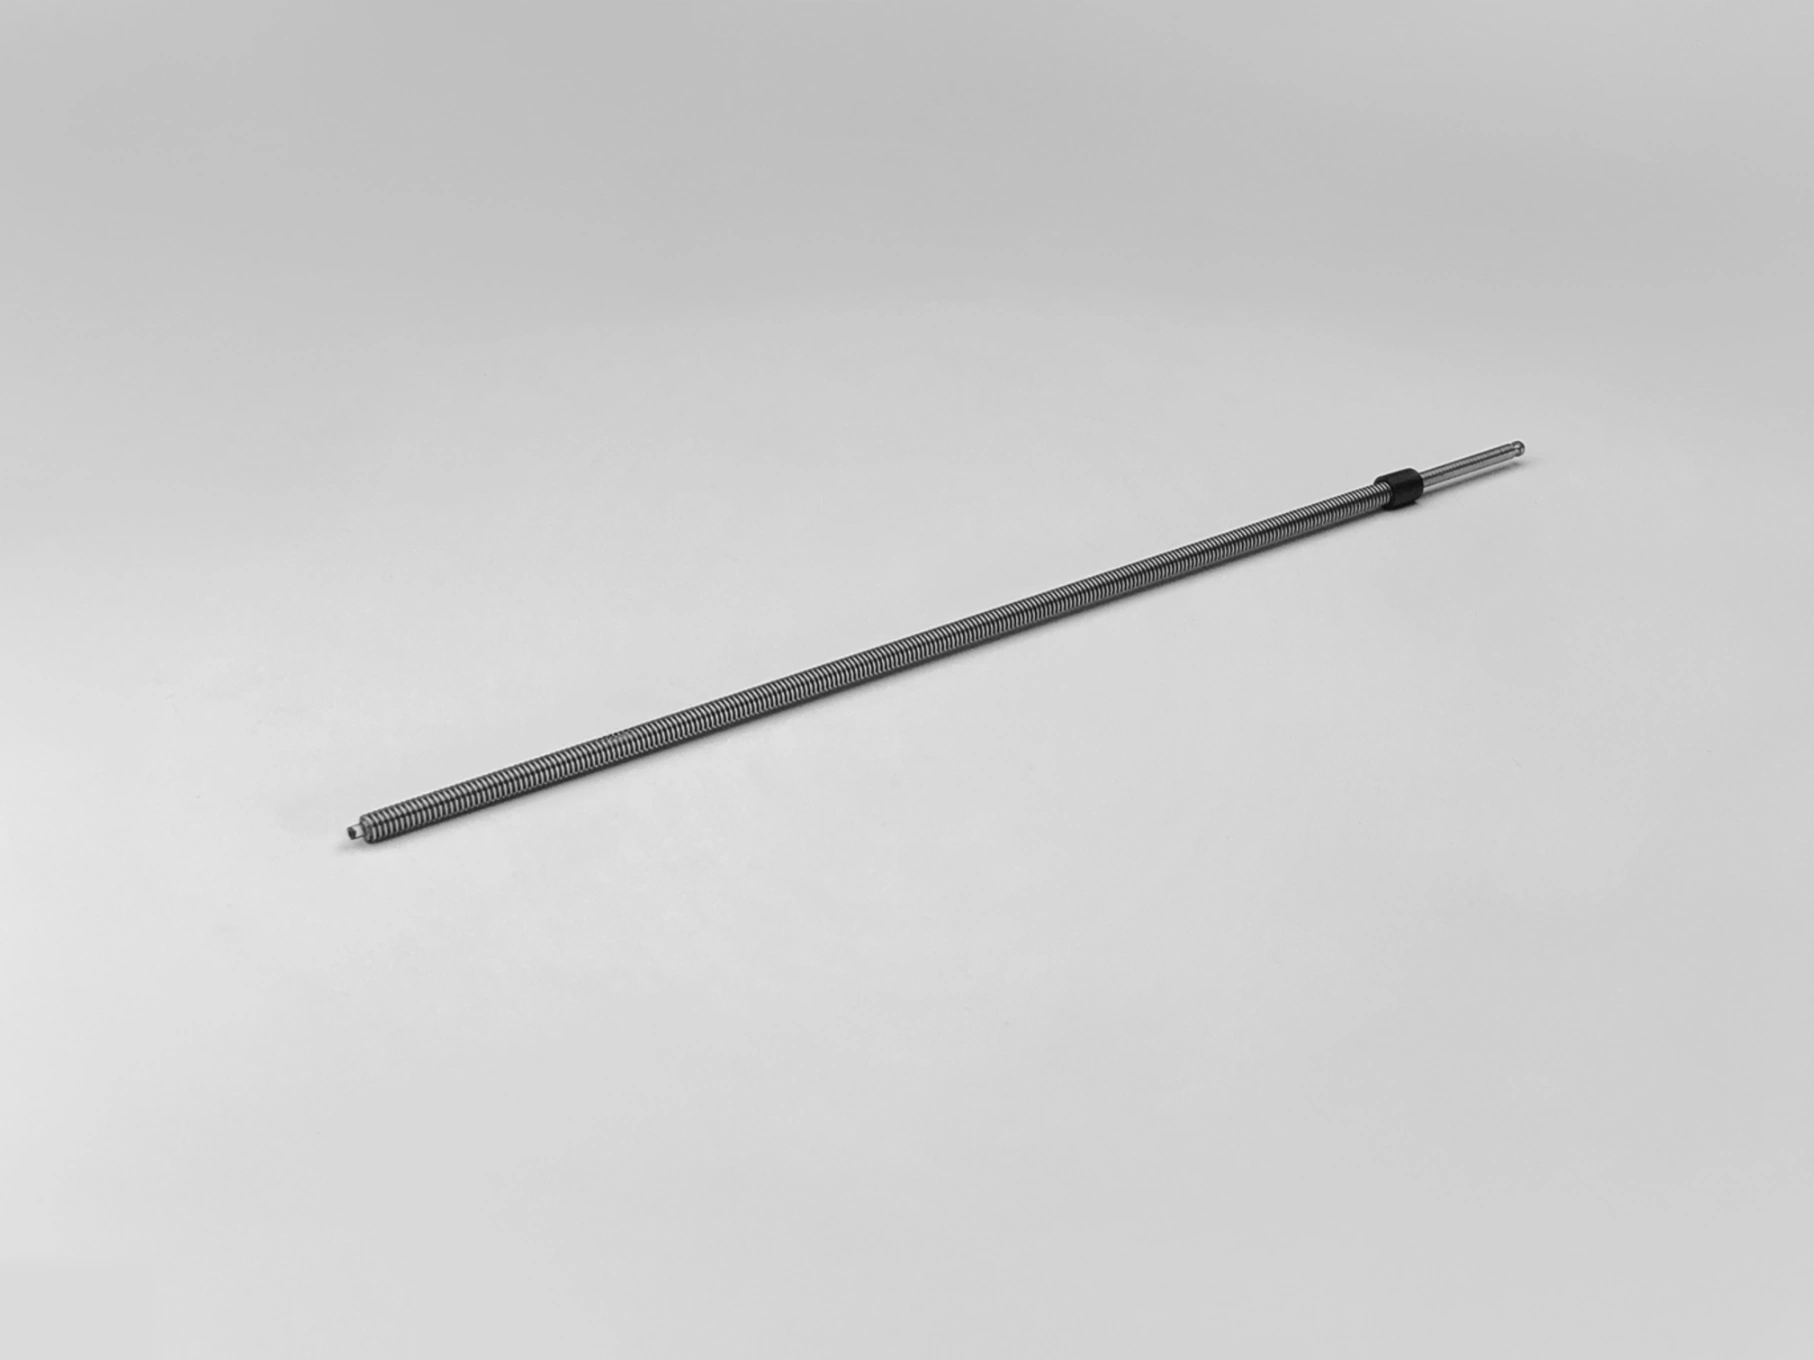
Instrument Shaft
HA-IN-001
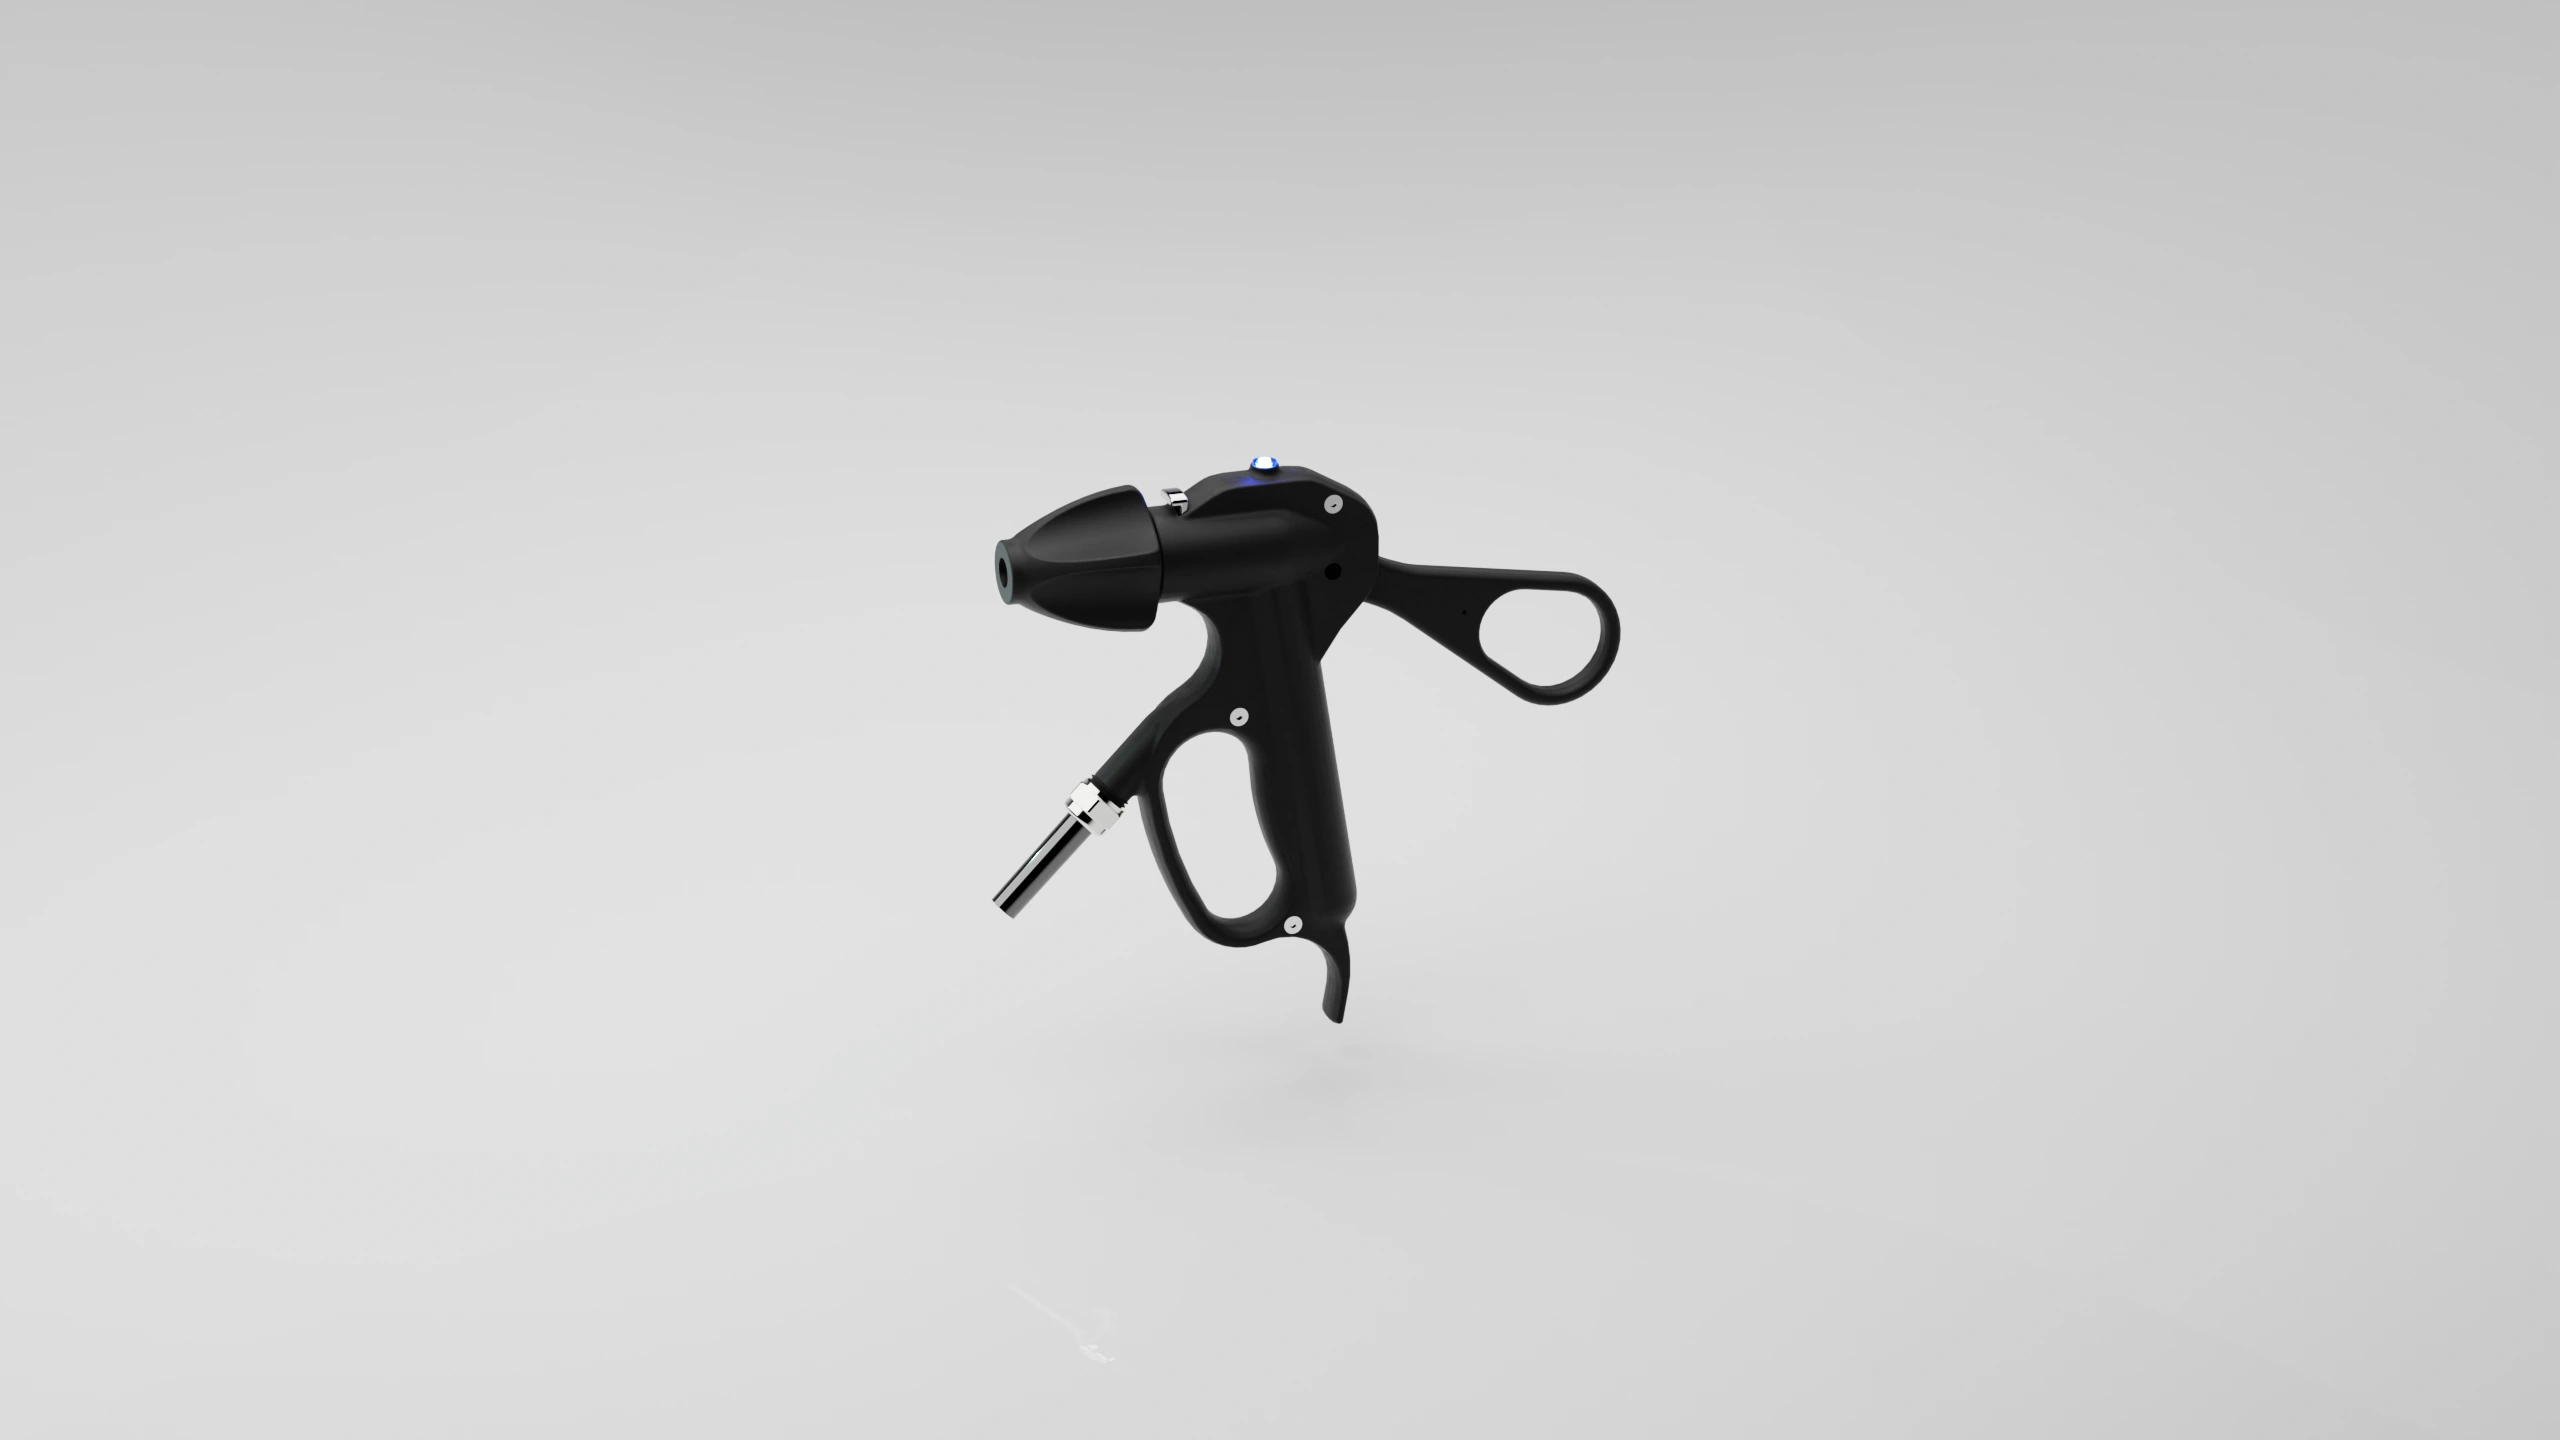
Grasper
HA-IN-002
-
Grasper Without Force
HA-IN-003
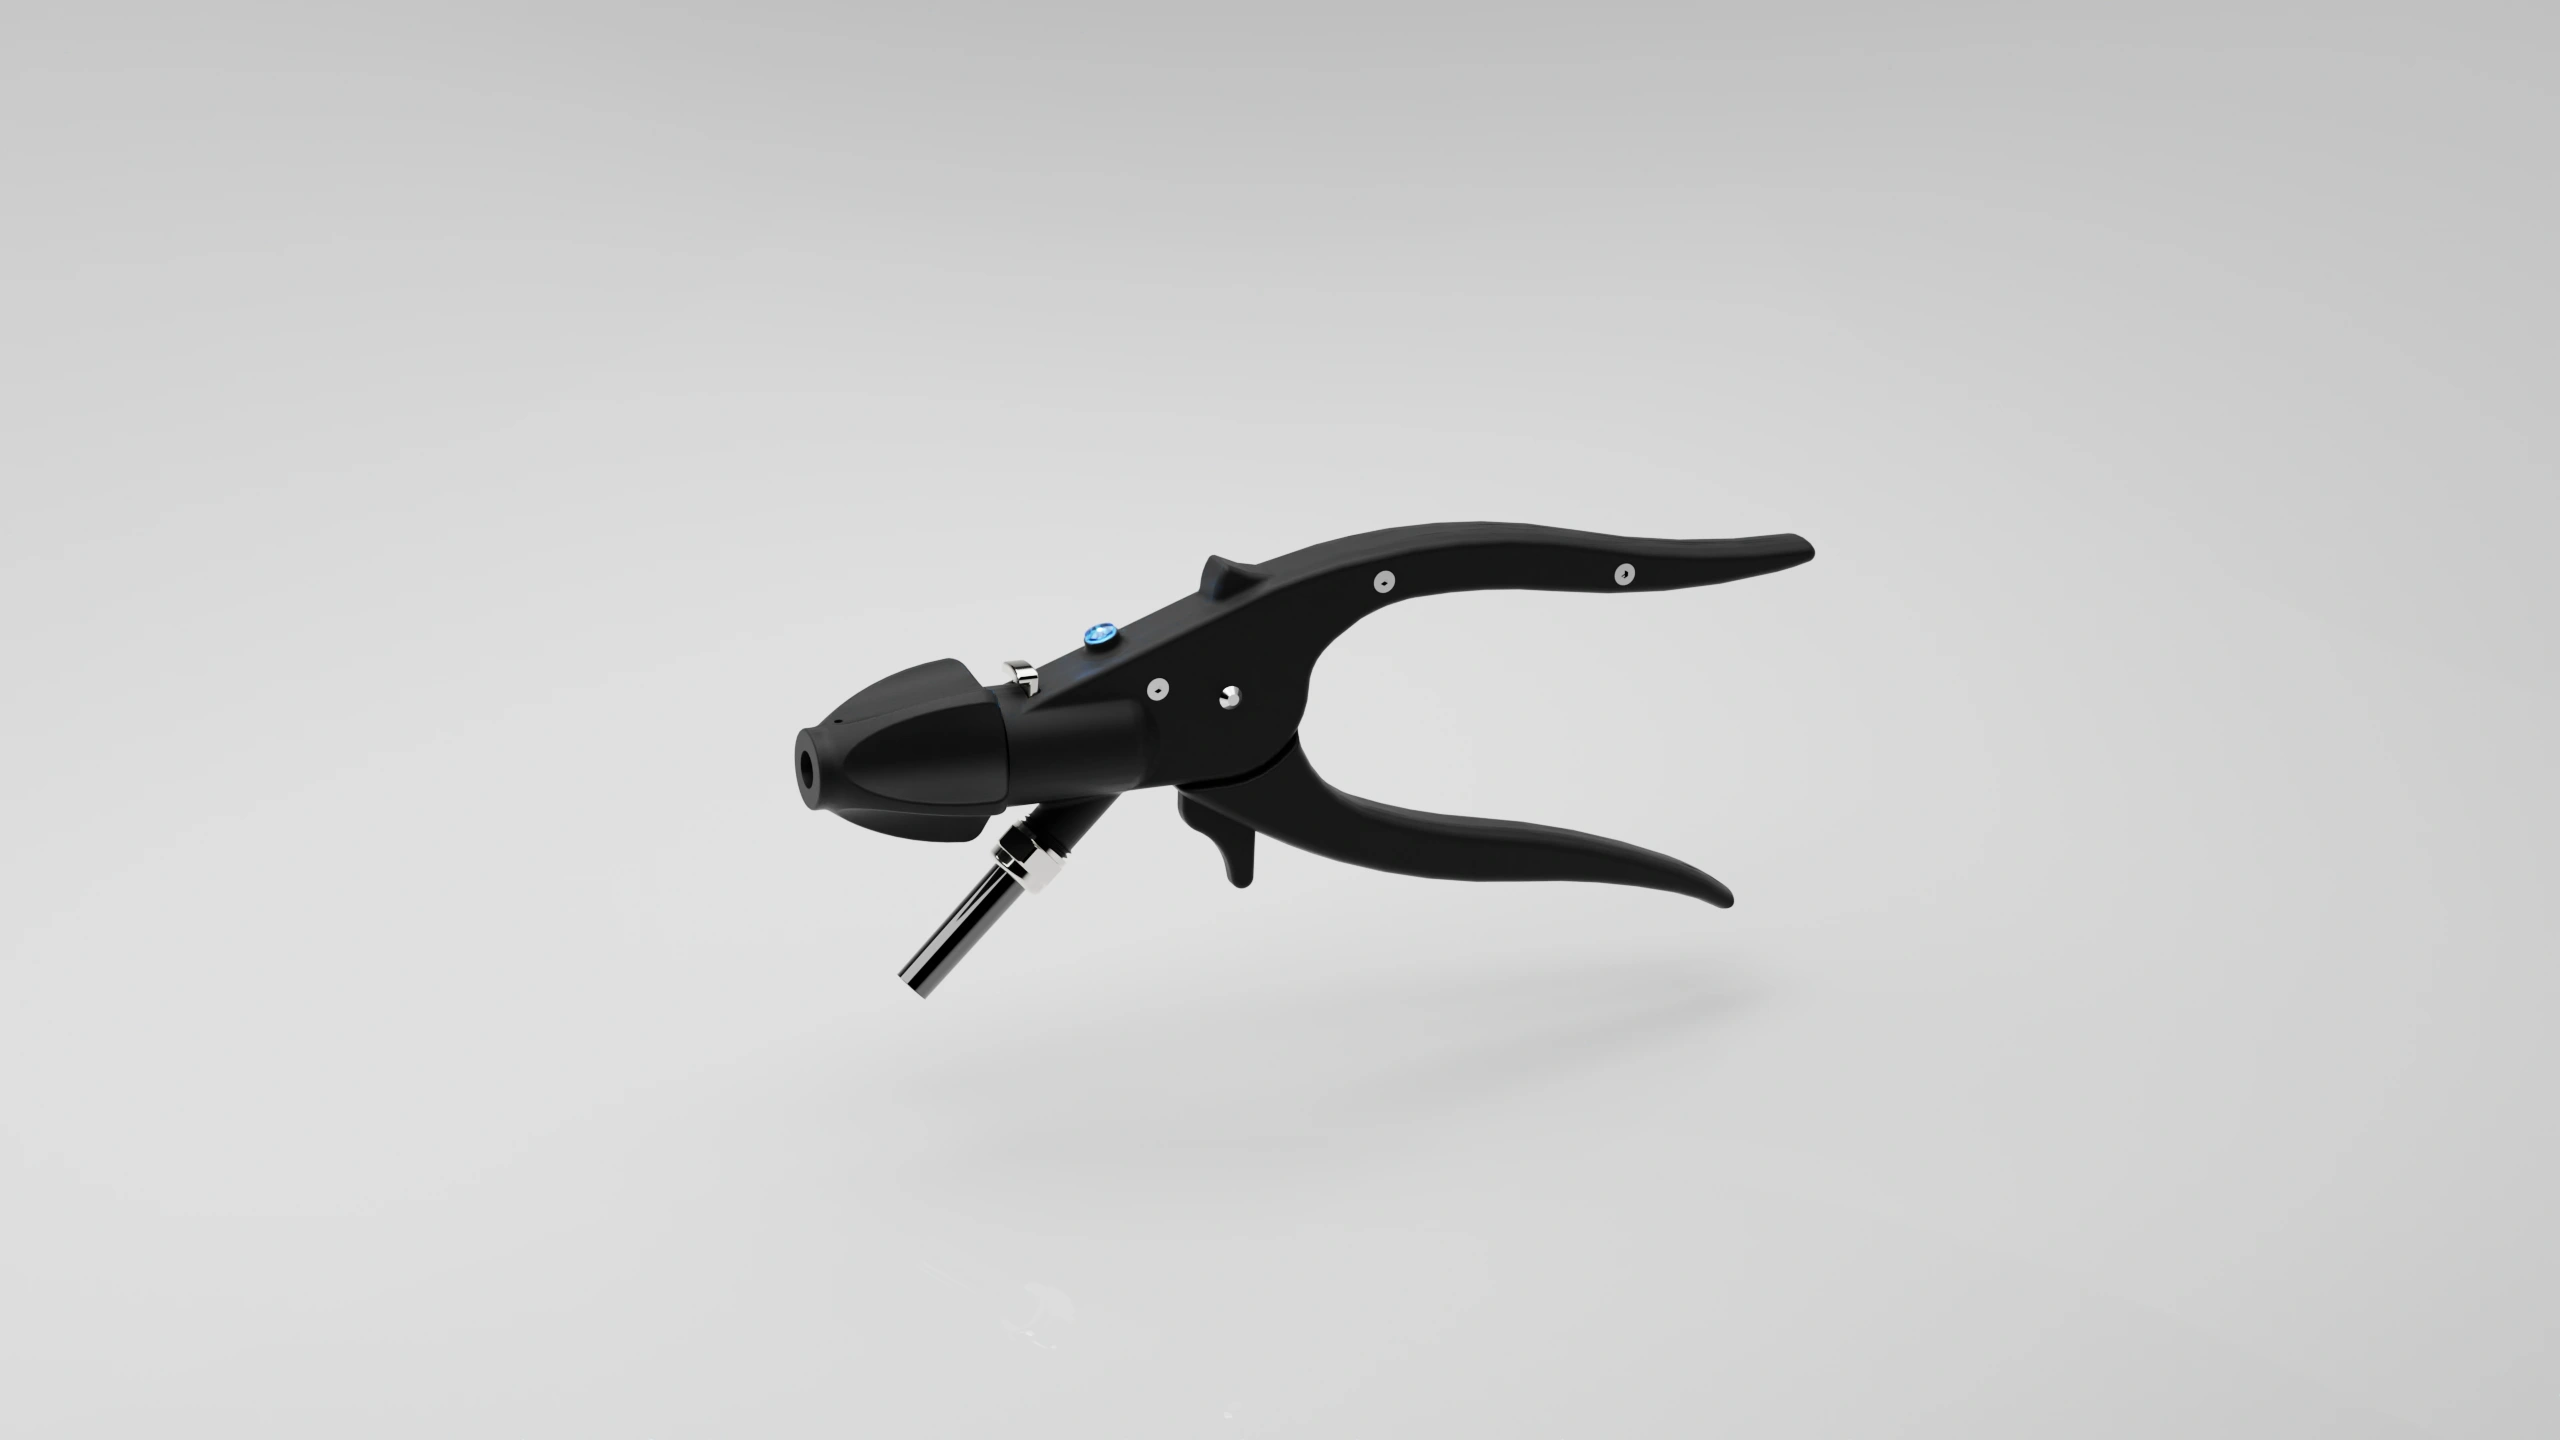
Needle Driver
HA-IN-004
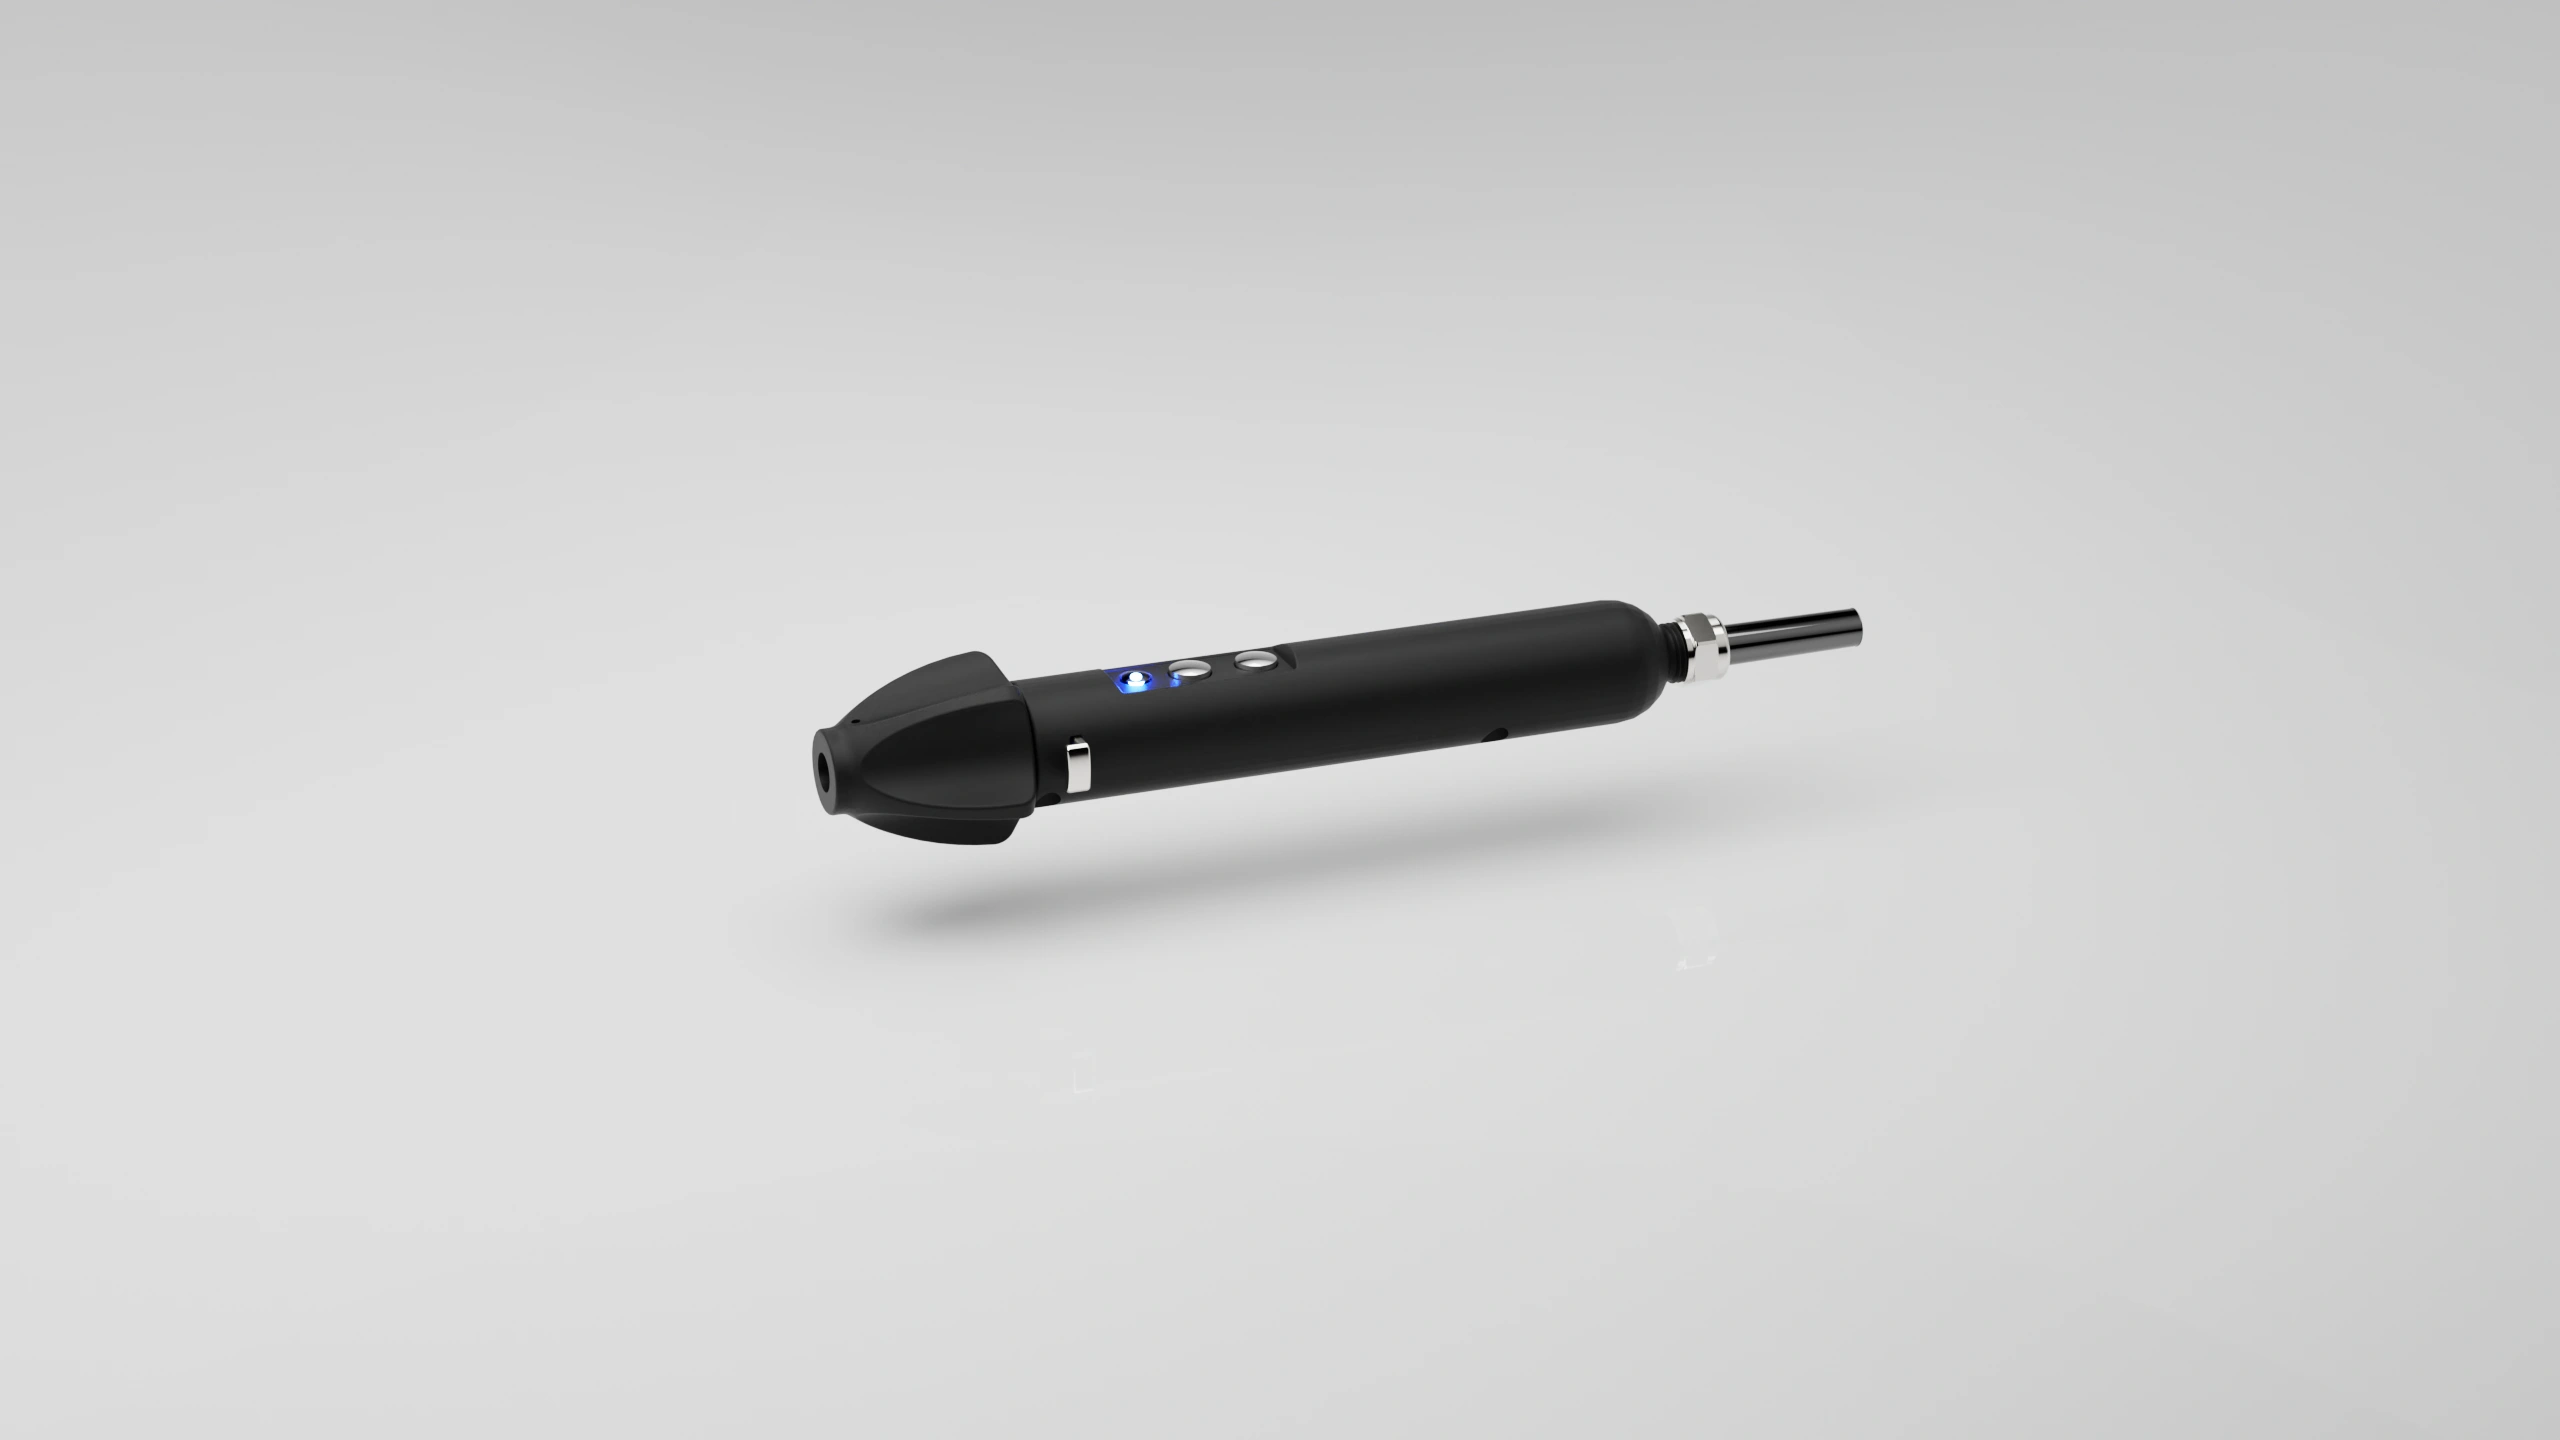
Straight Tool With Pushbuttons
HA-IN-005
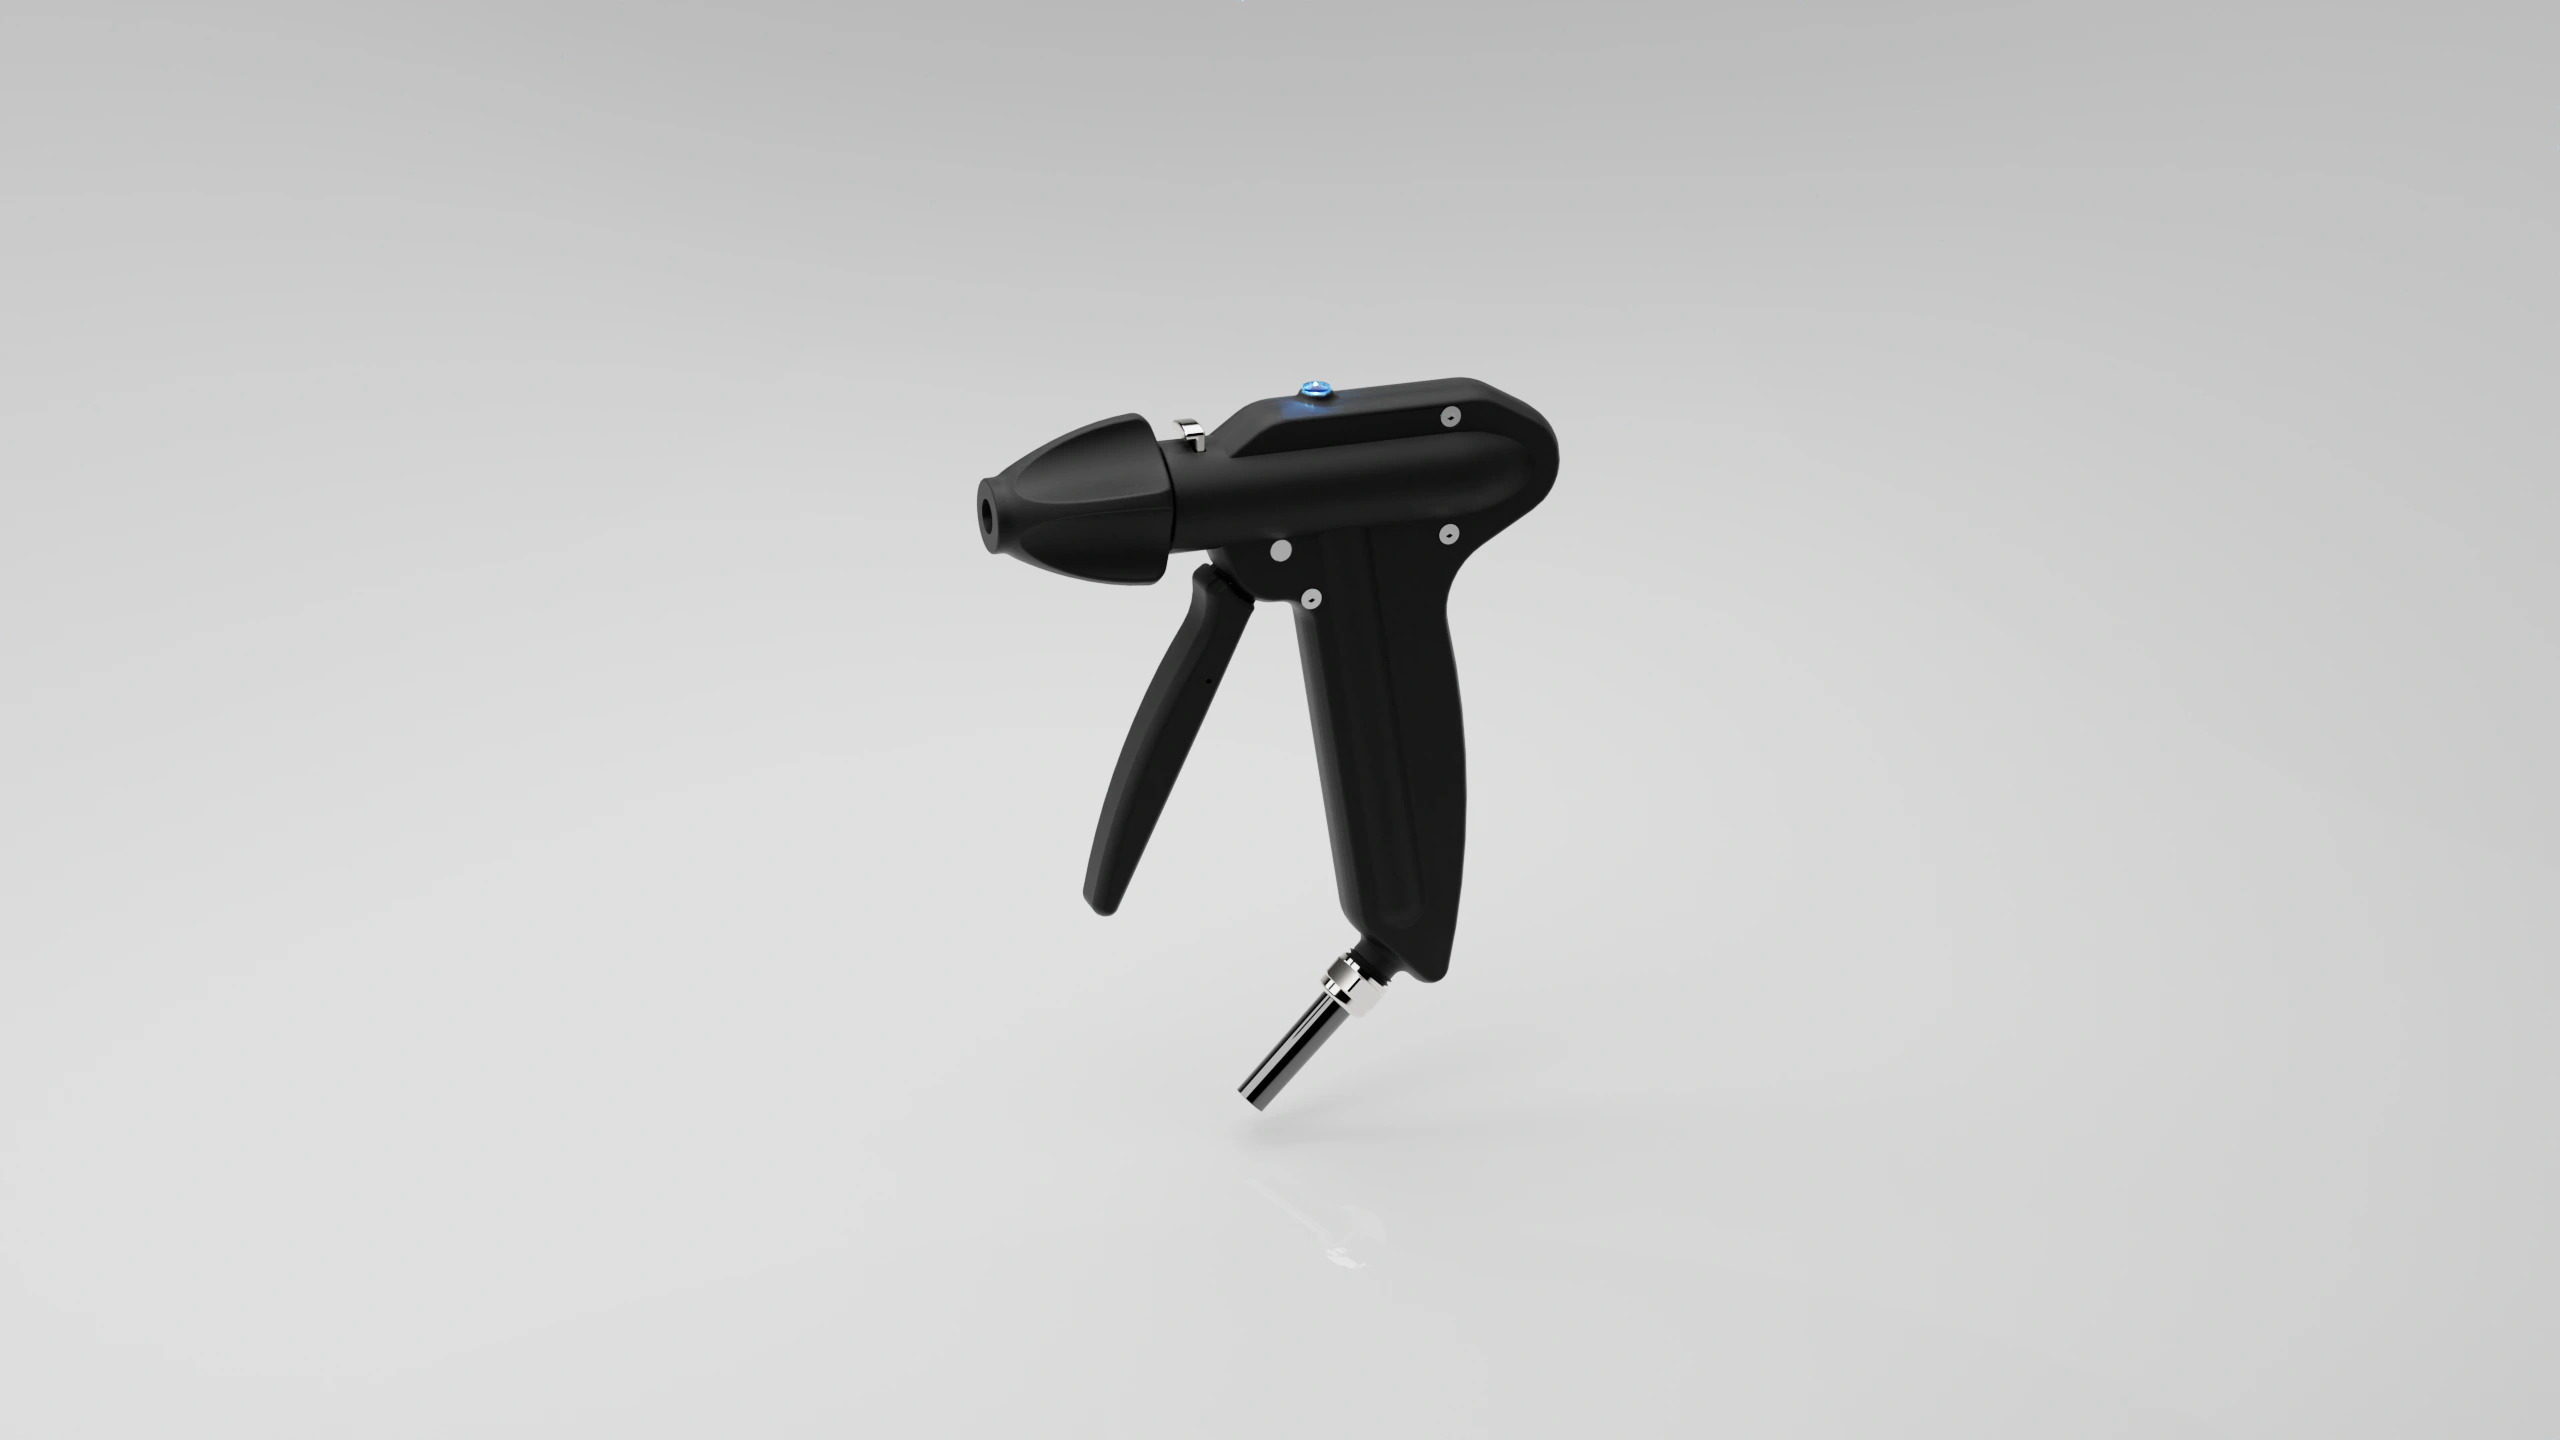
Clip Applier
HA-IN-006
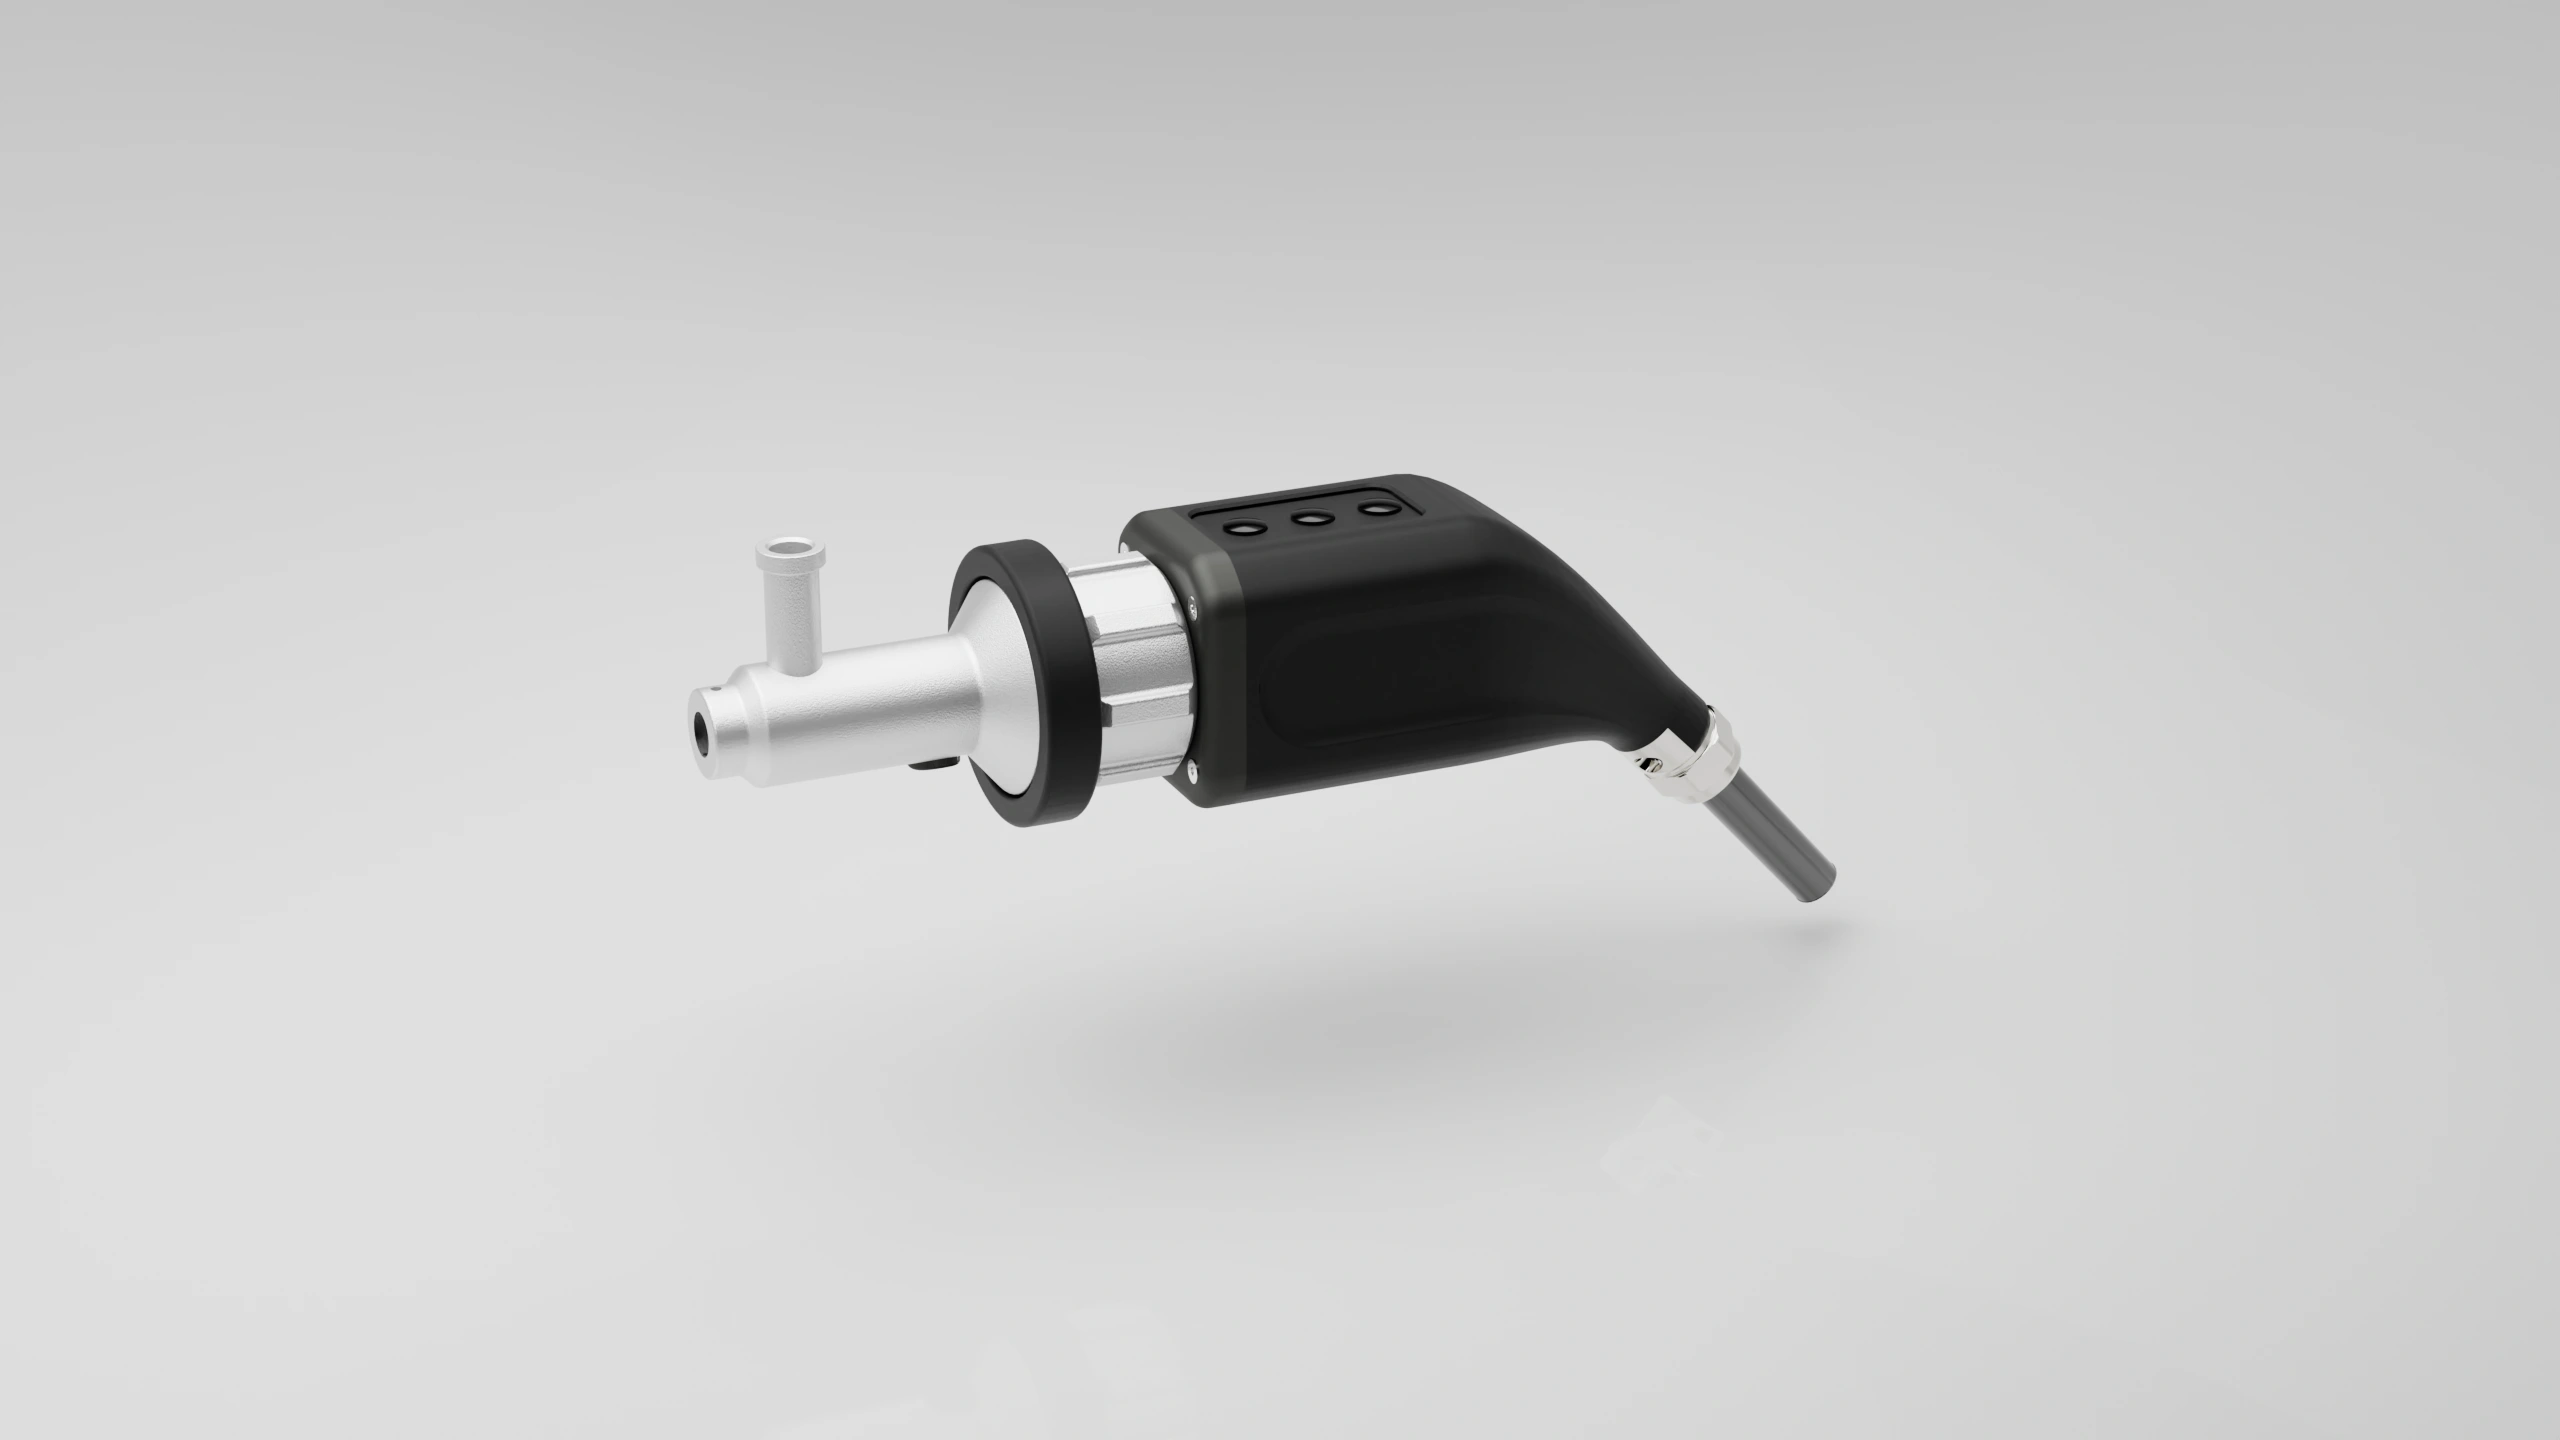
Scope
HA-SD-001
Structures
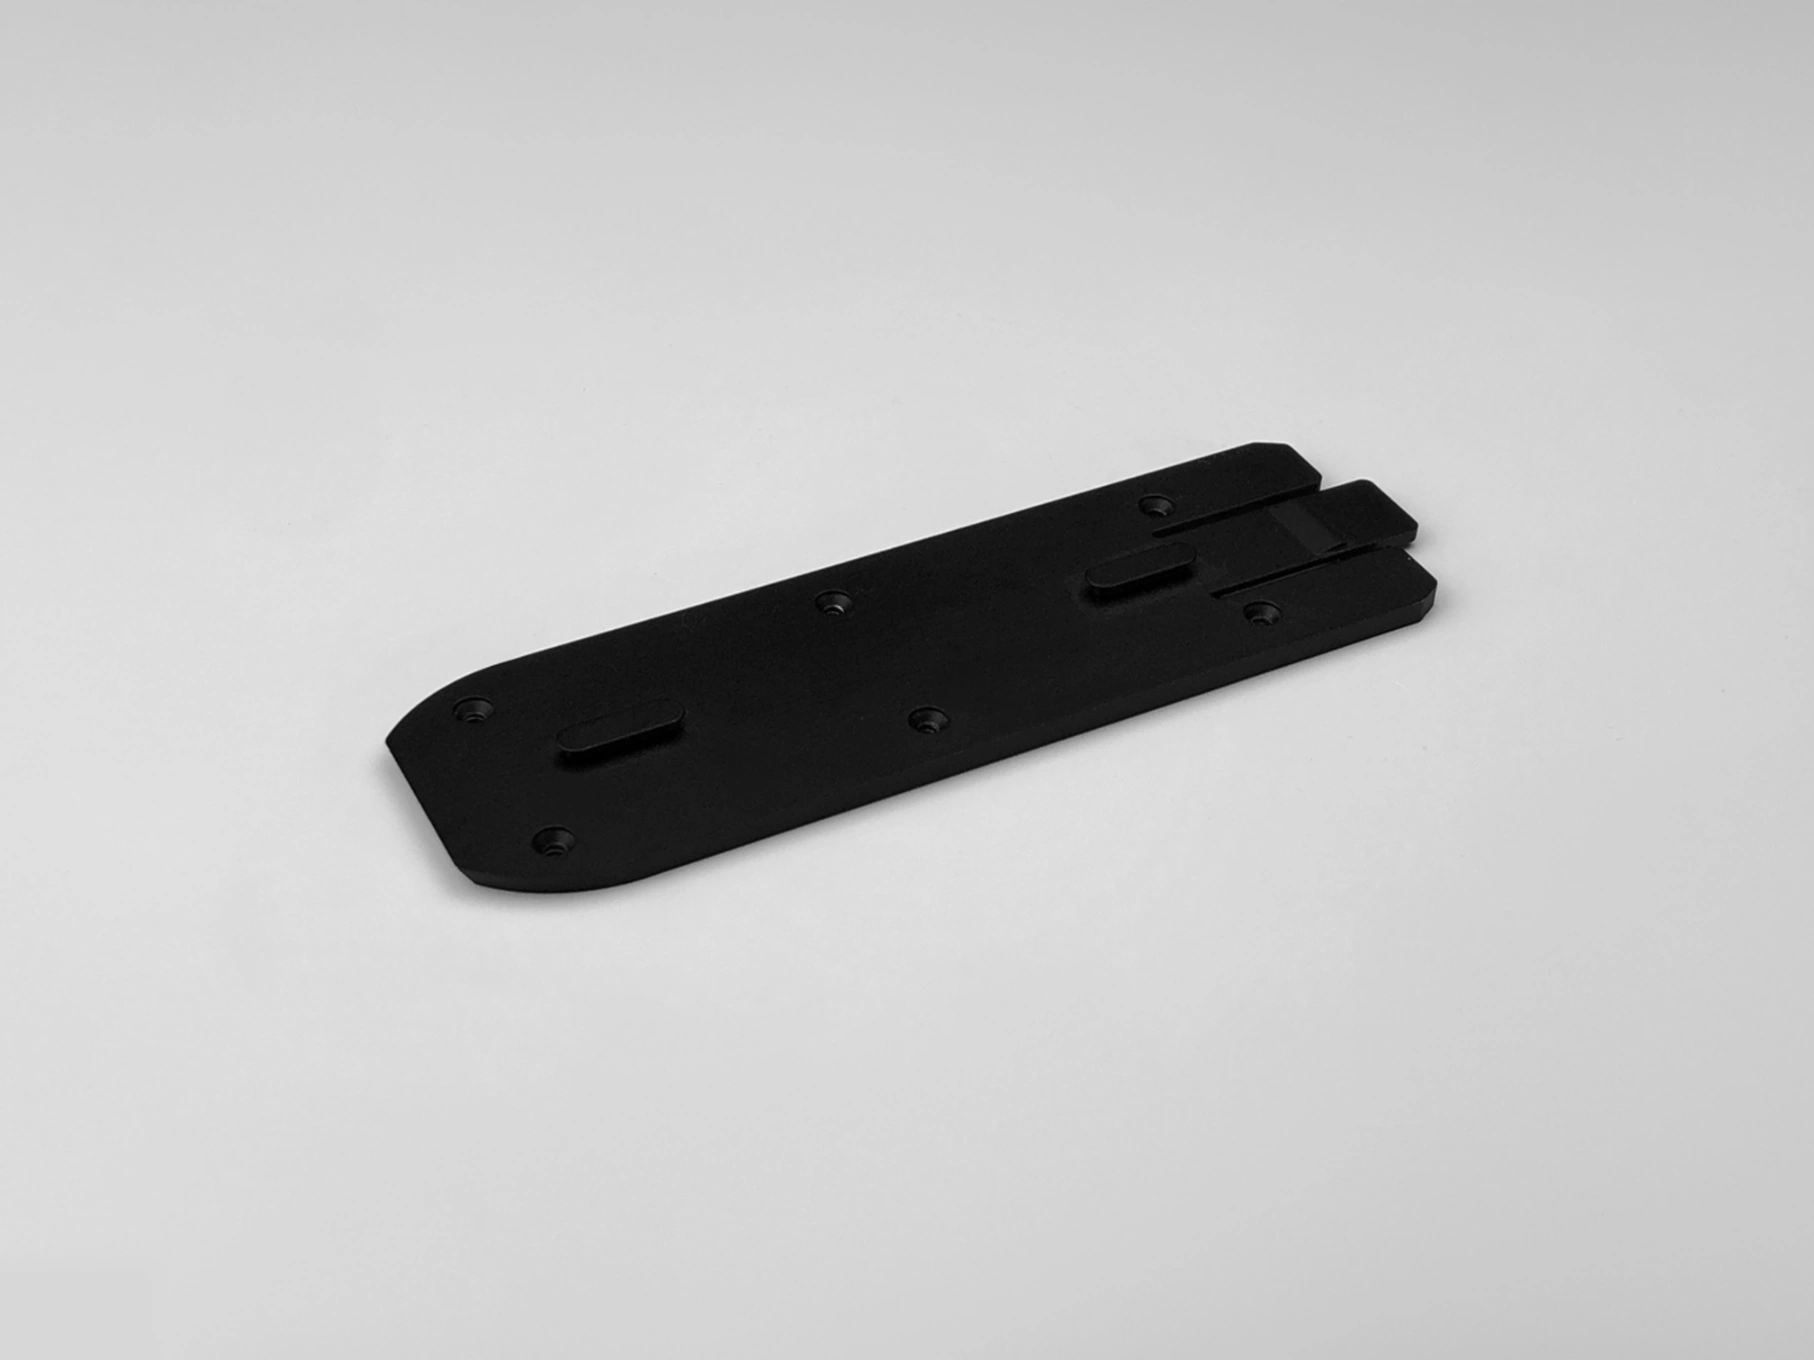
Haptic Port Mounting Bracket
HA-FA-001
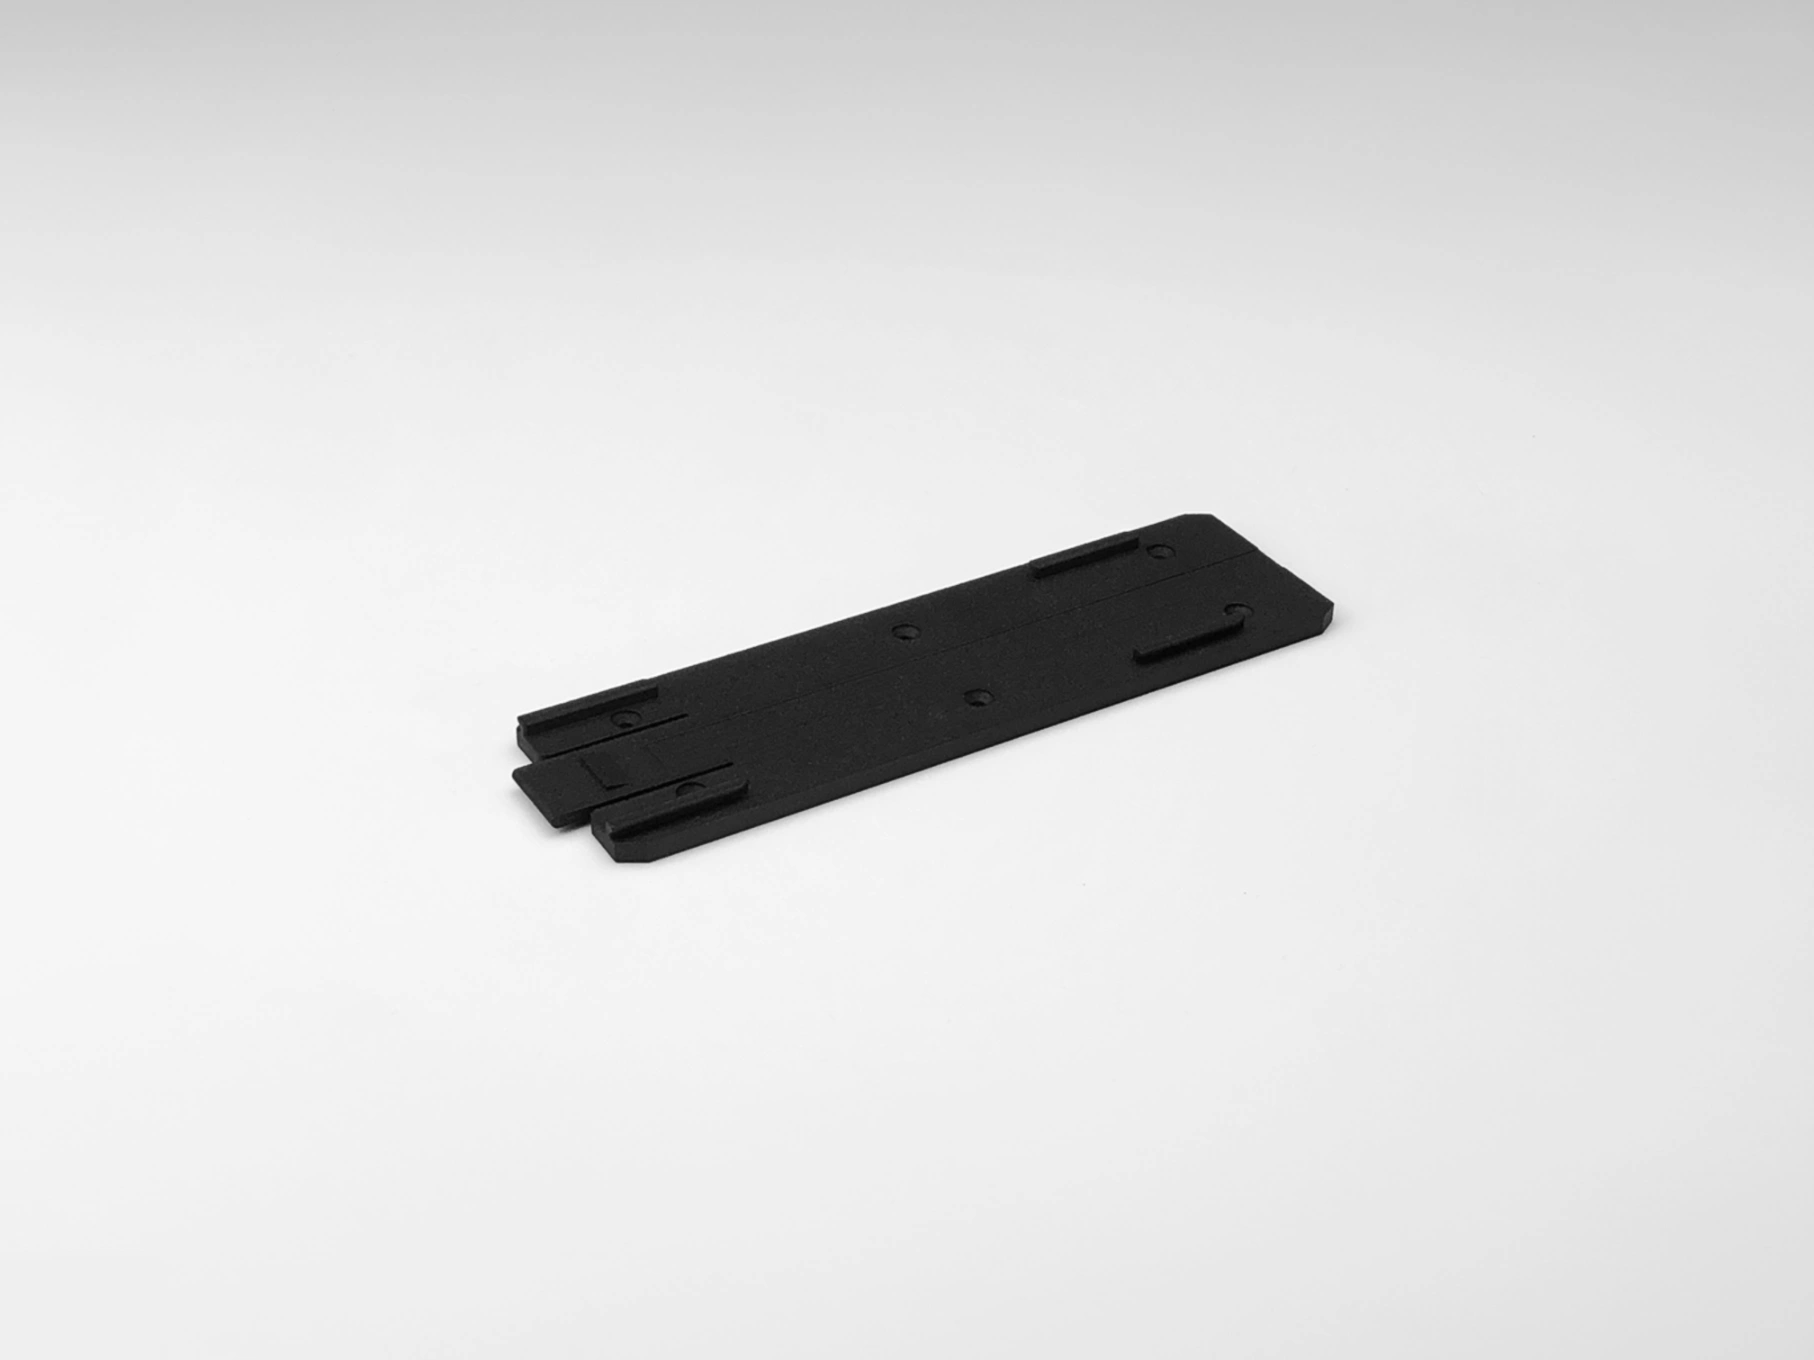
IBox Mounting Bracket
HA-FA-002
-
Fixed 20° Ramp Low
HA-FA-003
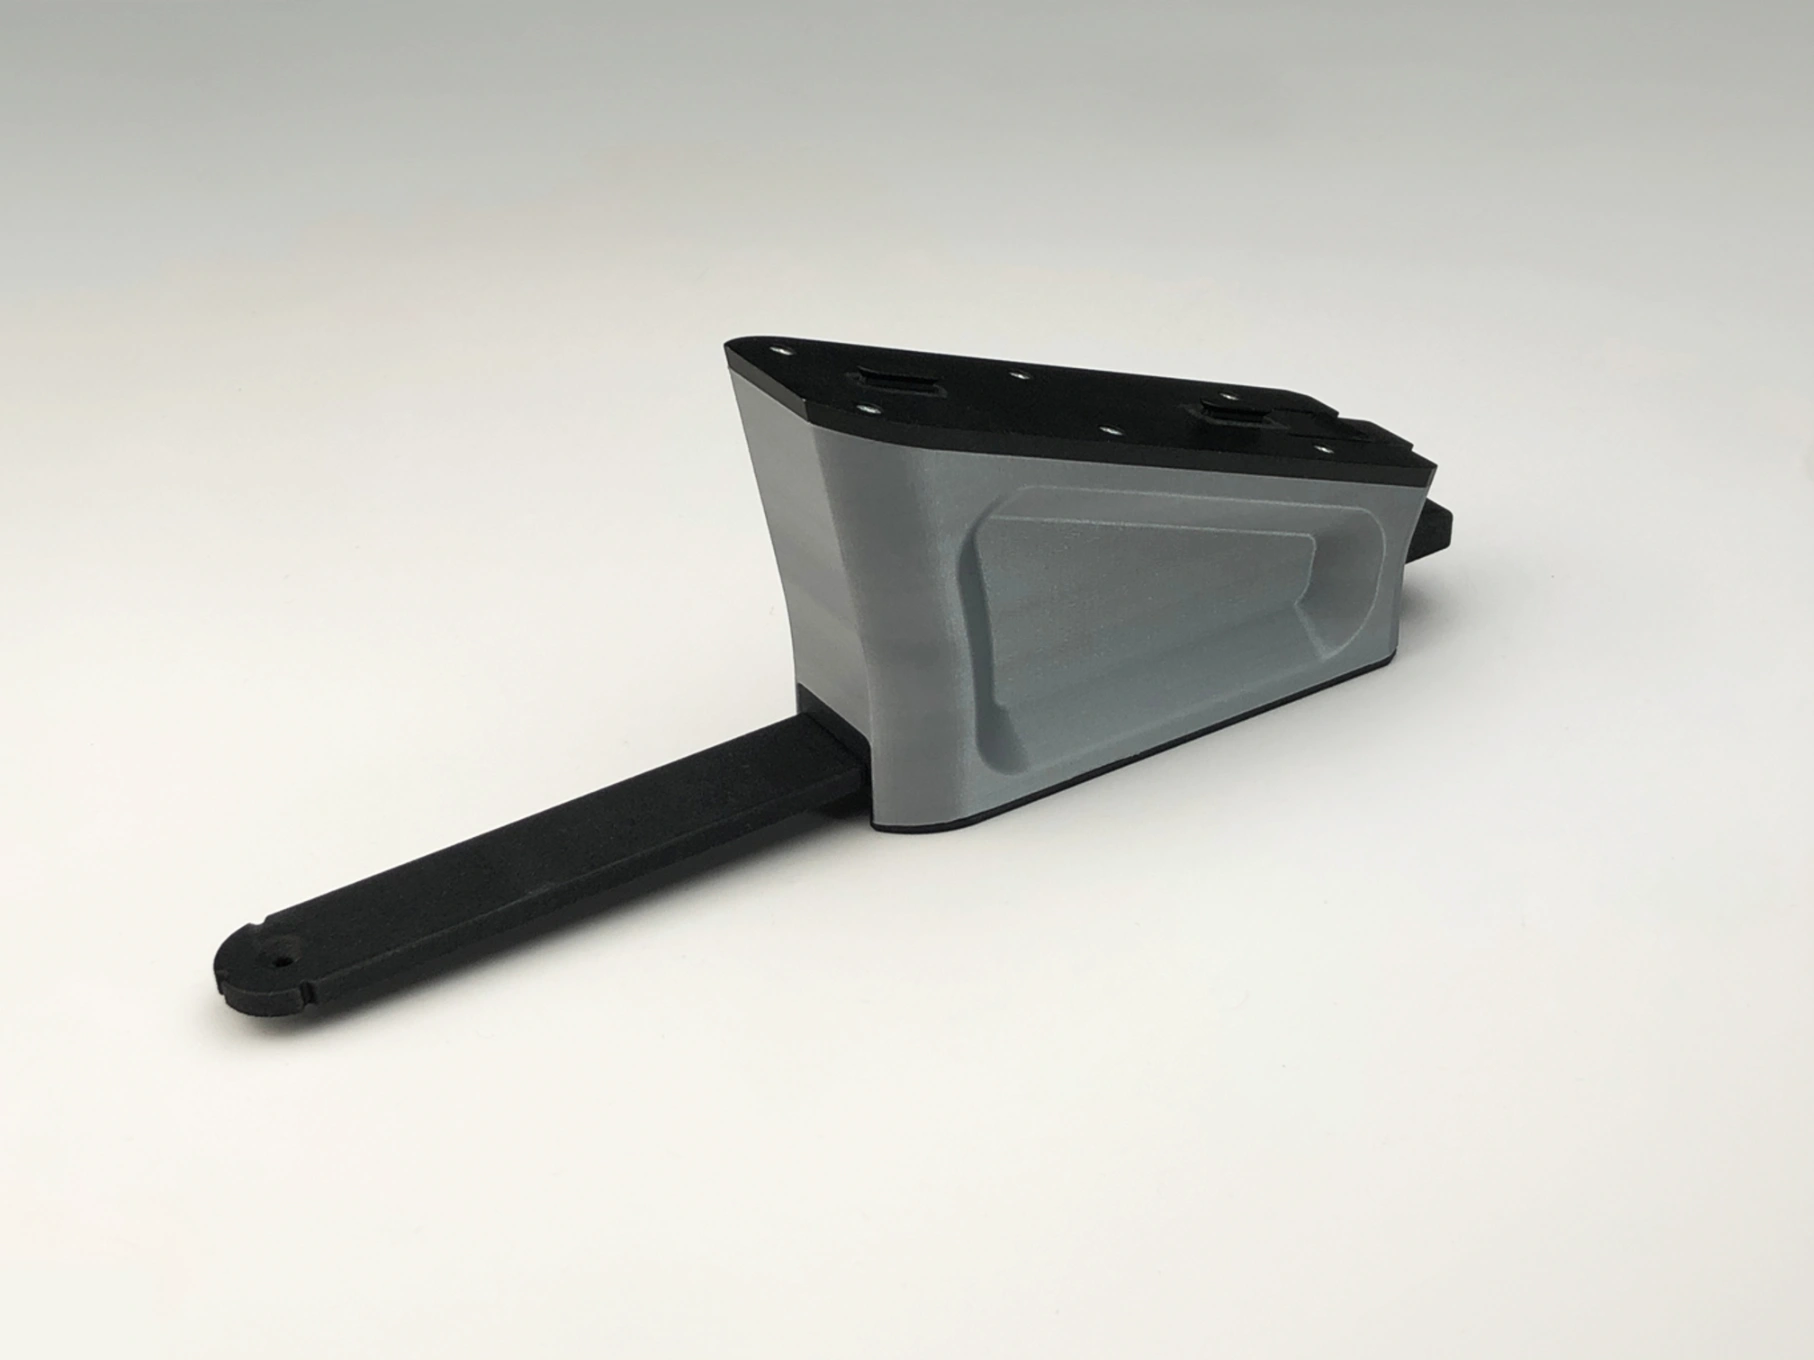
Movable 20° ramp Low
HA-FA-005
-
Base With 5 Rails
HA-BA-001
-
Workstation Base With 2 Mounting Brackets
HA-BA-002
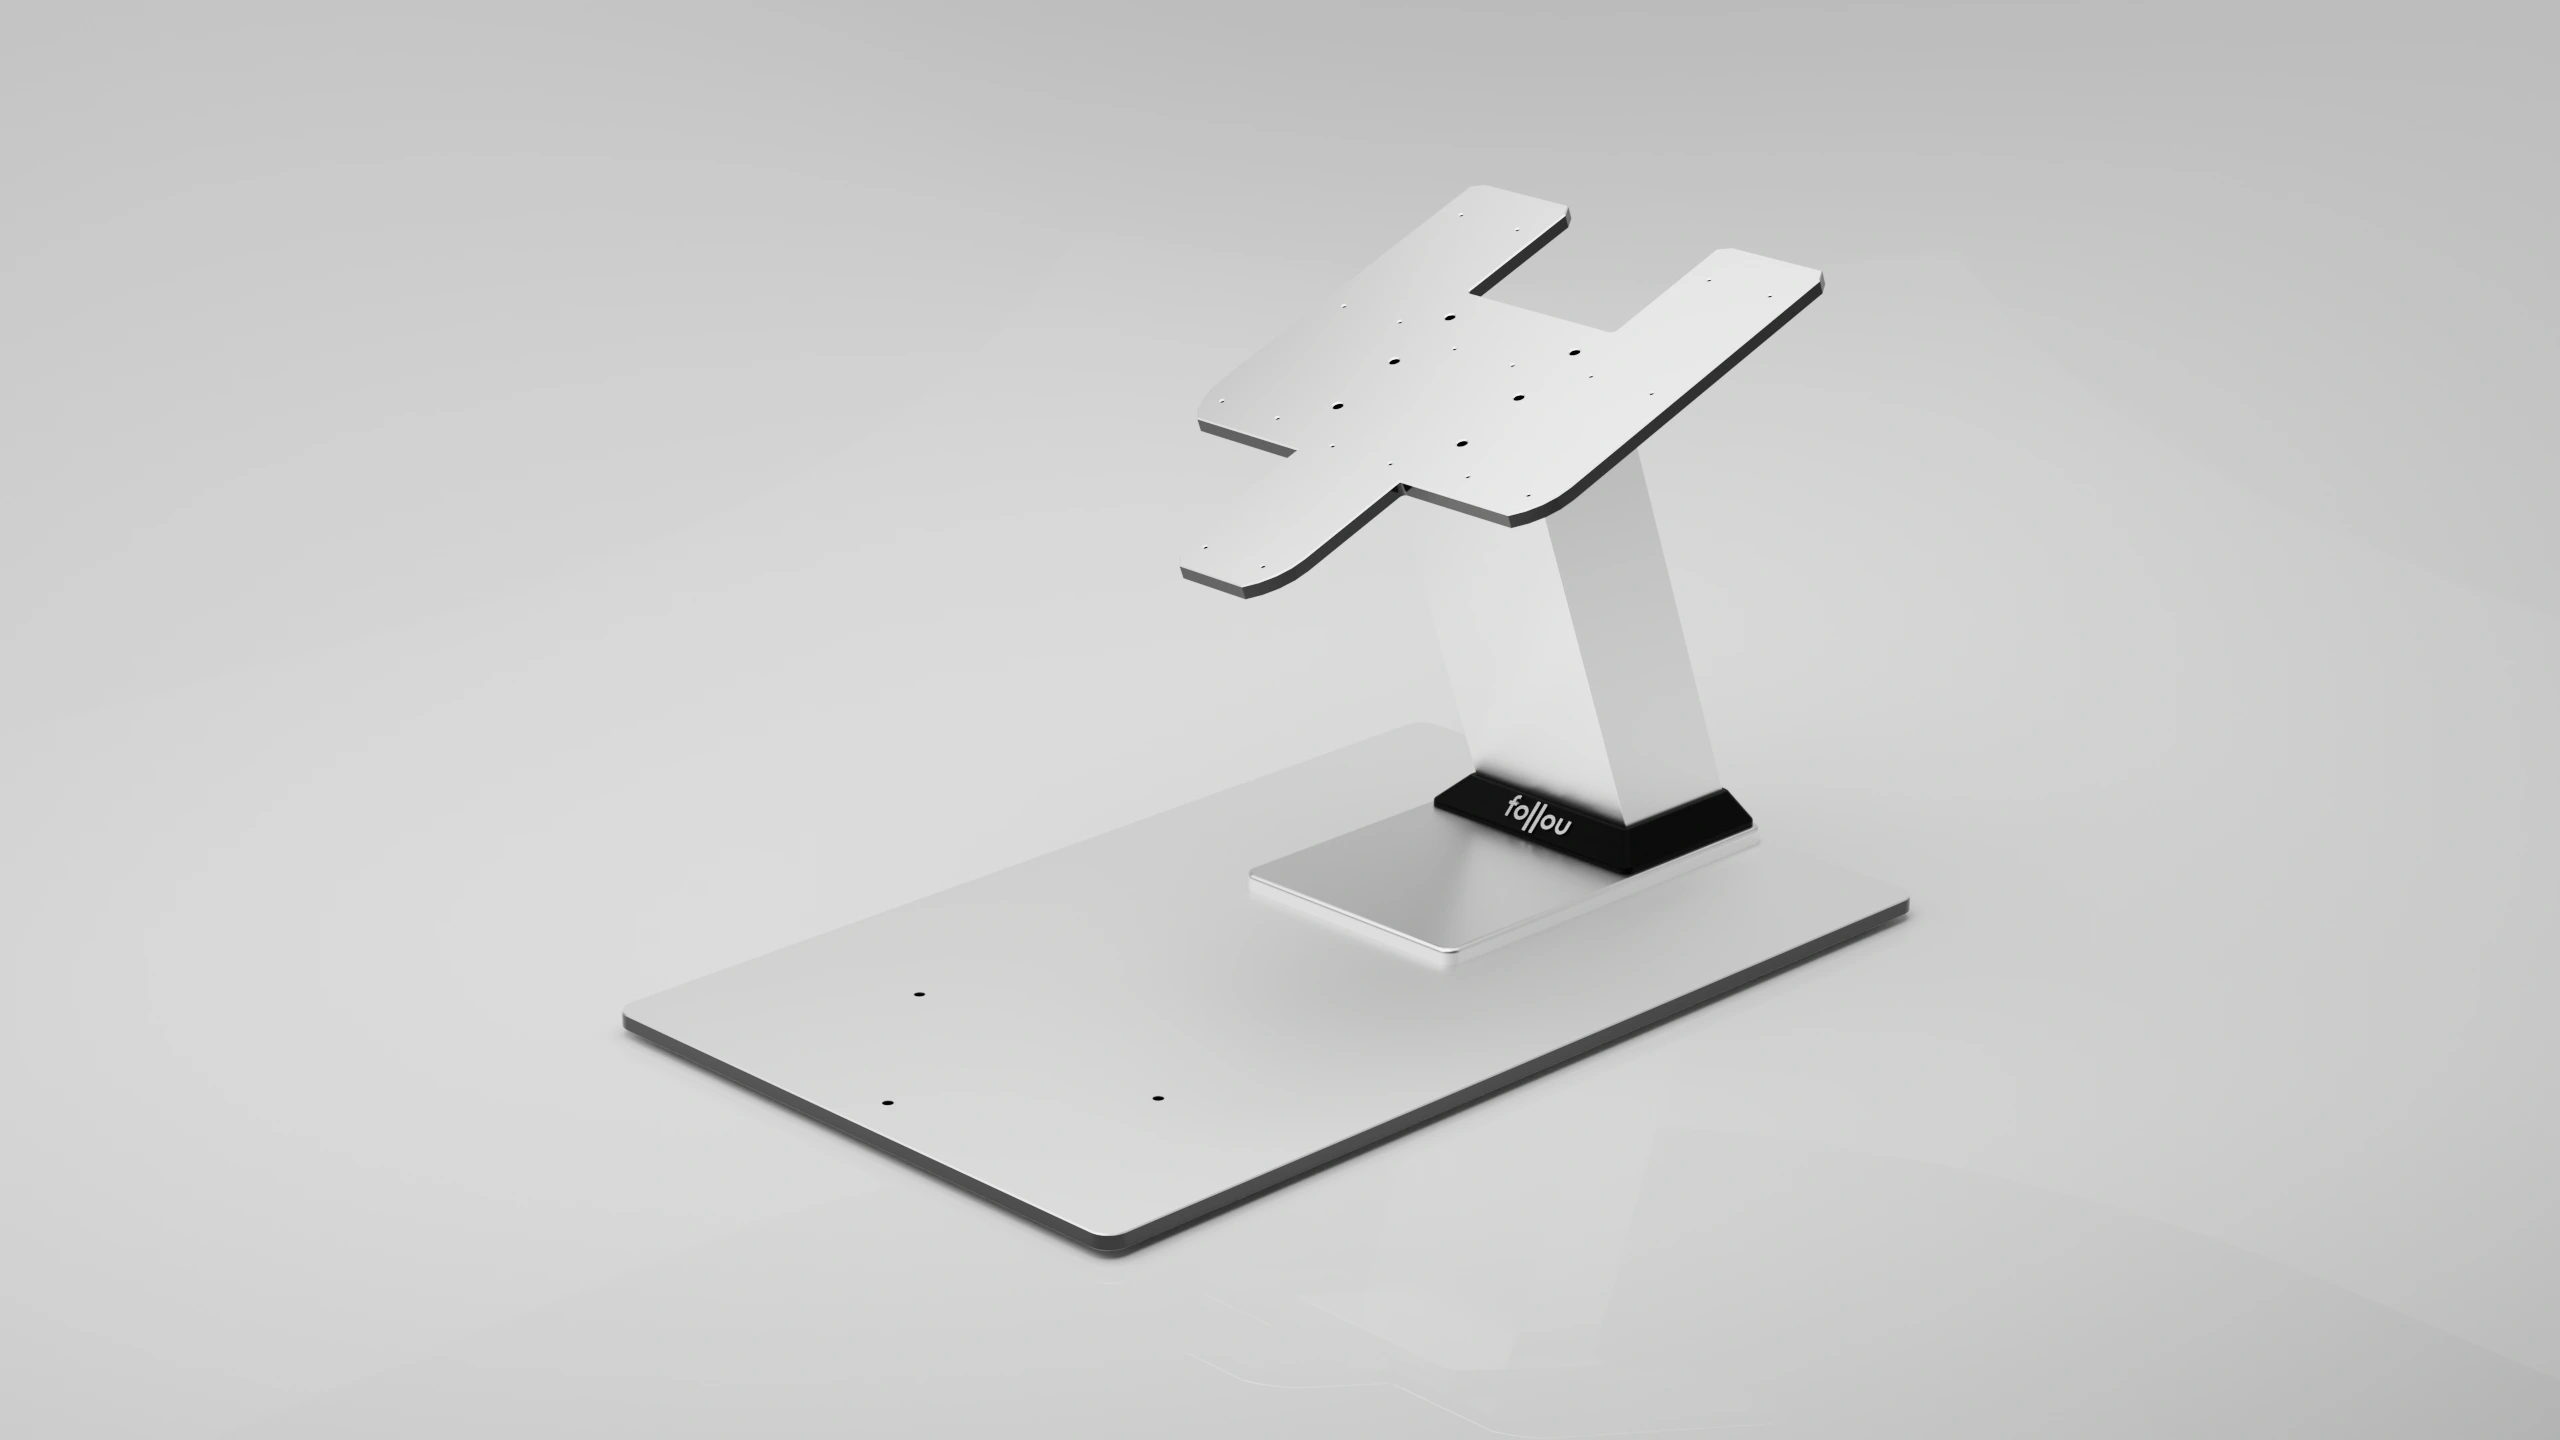
Workstation Base With 3 Mounting Brackets
HA-BA-003
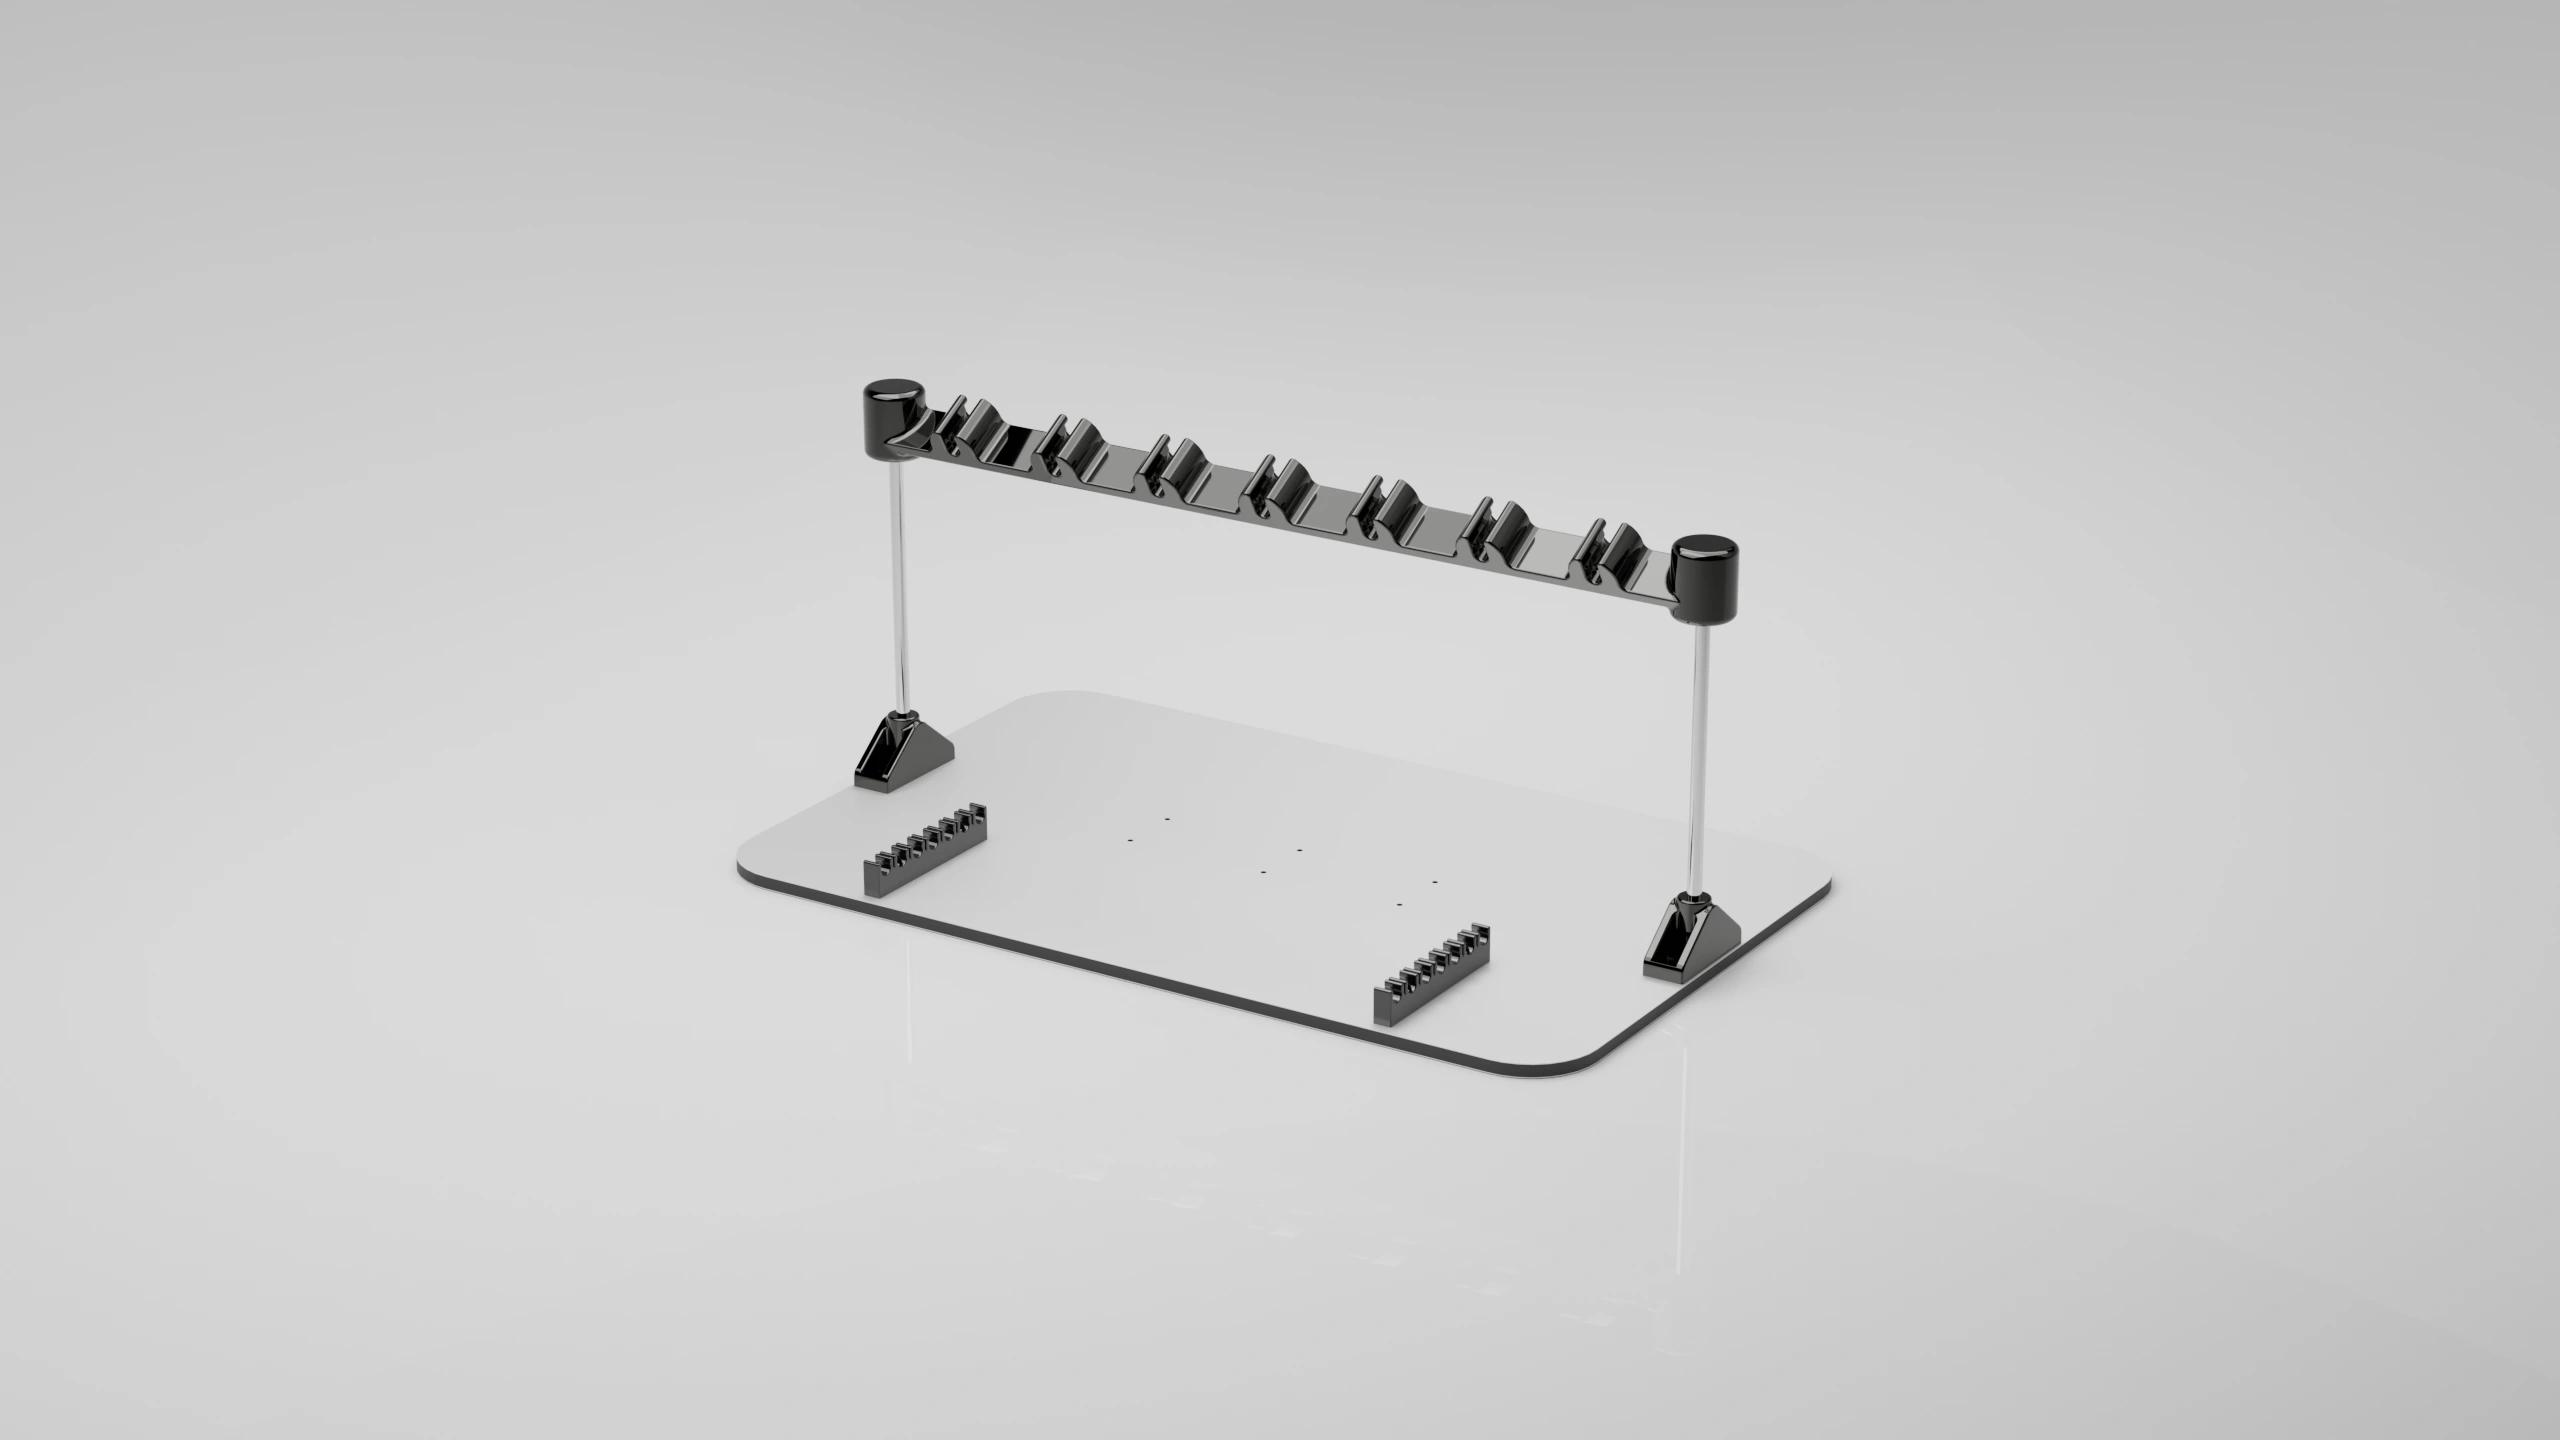
Instrument Holder Stand
HA-BA-004
Options and accessories
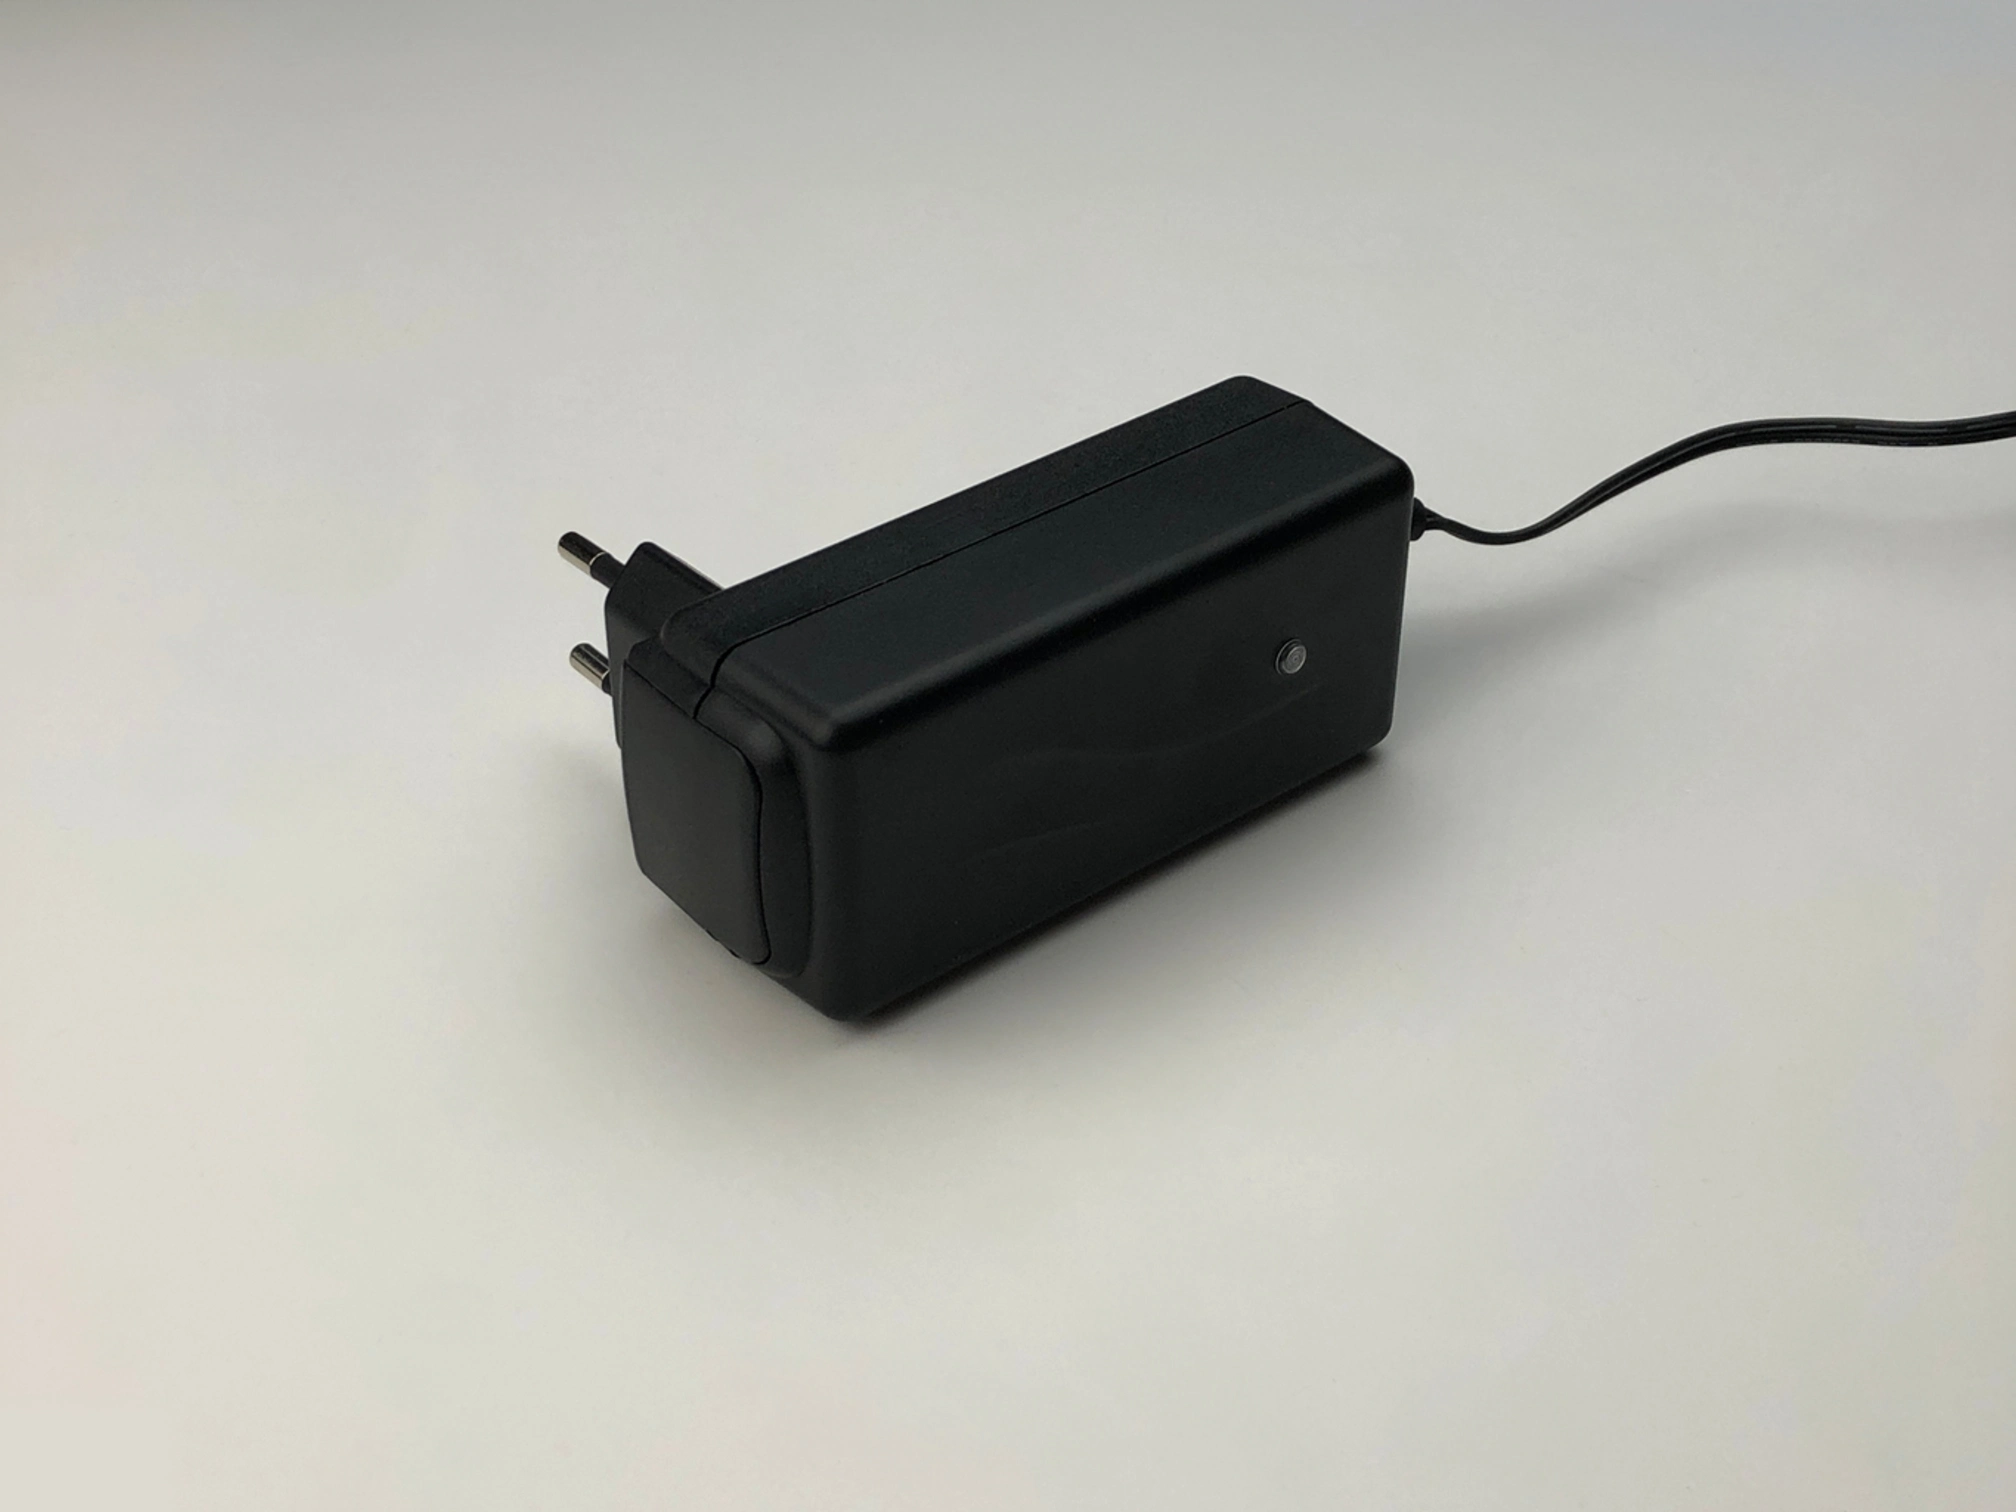
Li-Ion battery charger
HA-AC-001
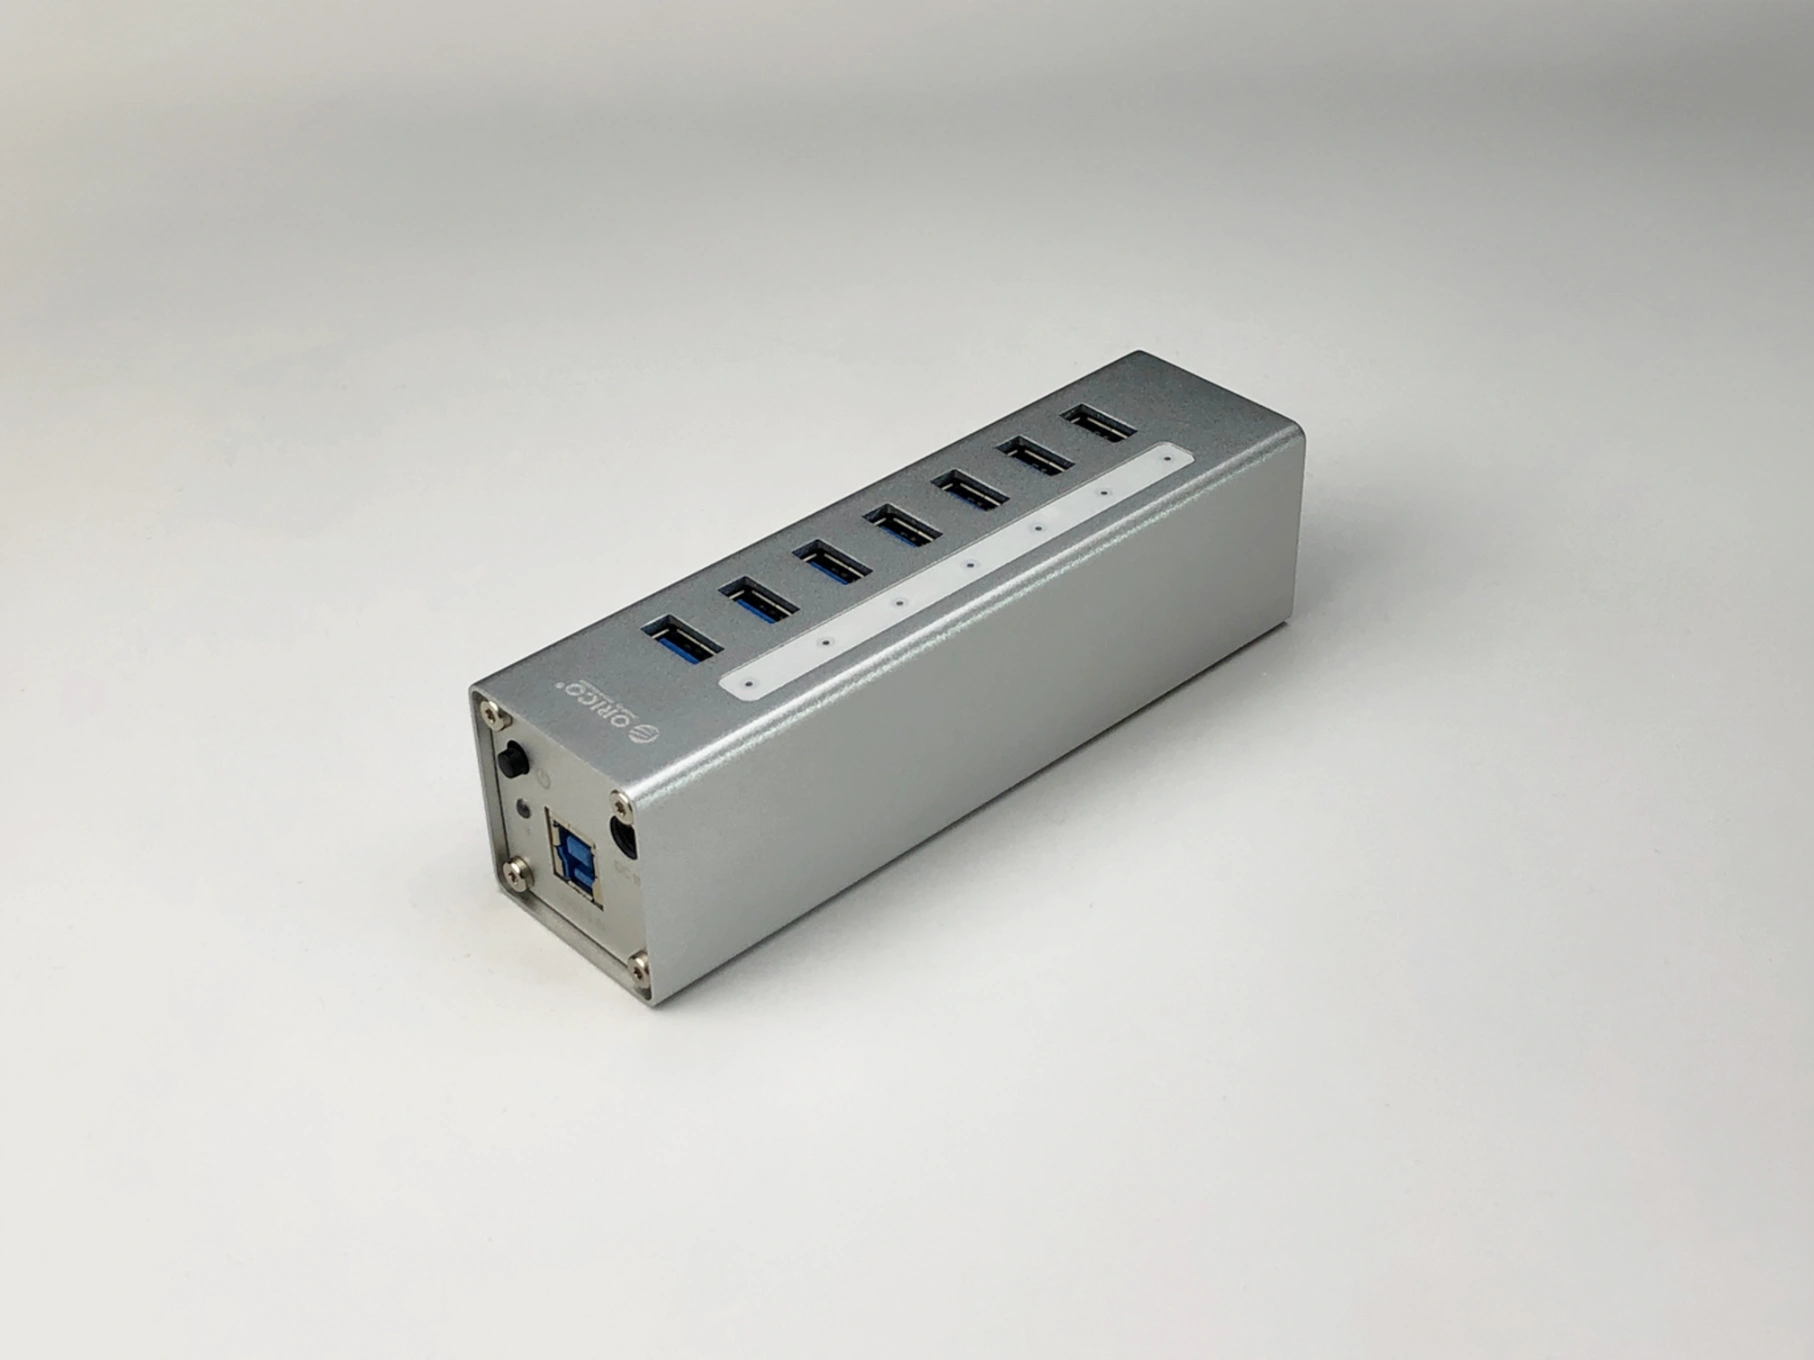
USB-hub
HA-AC-002
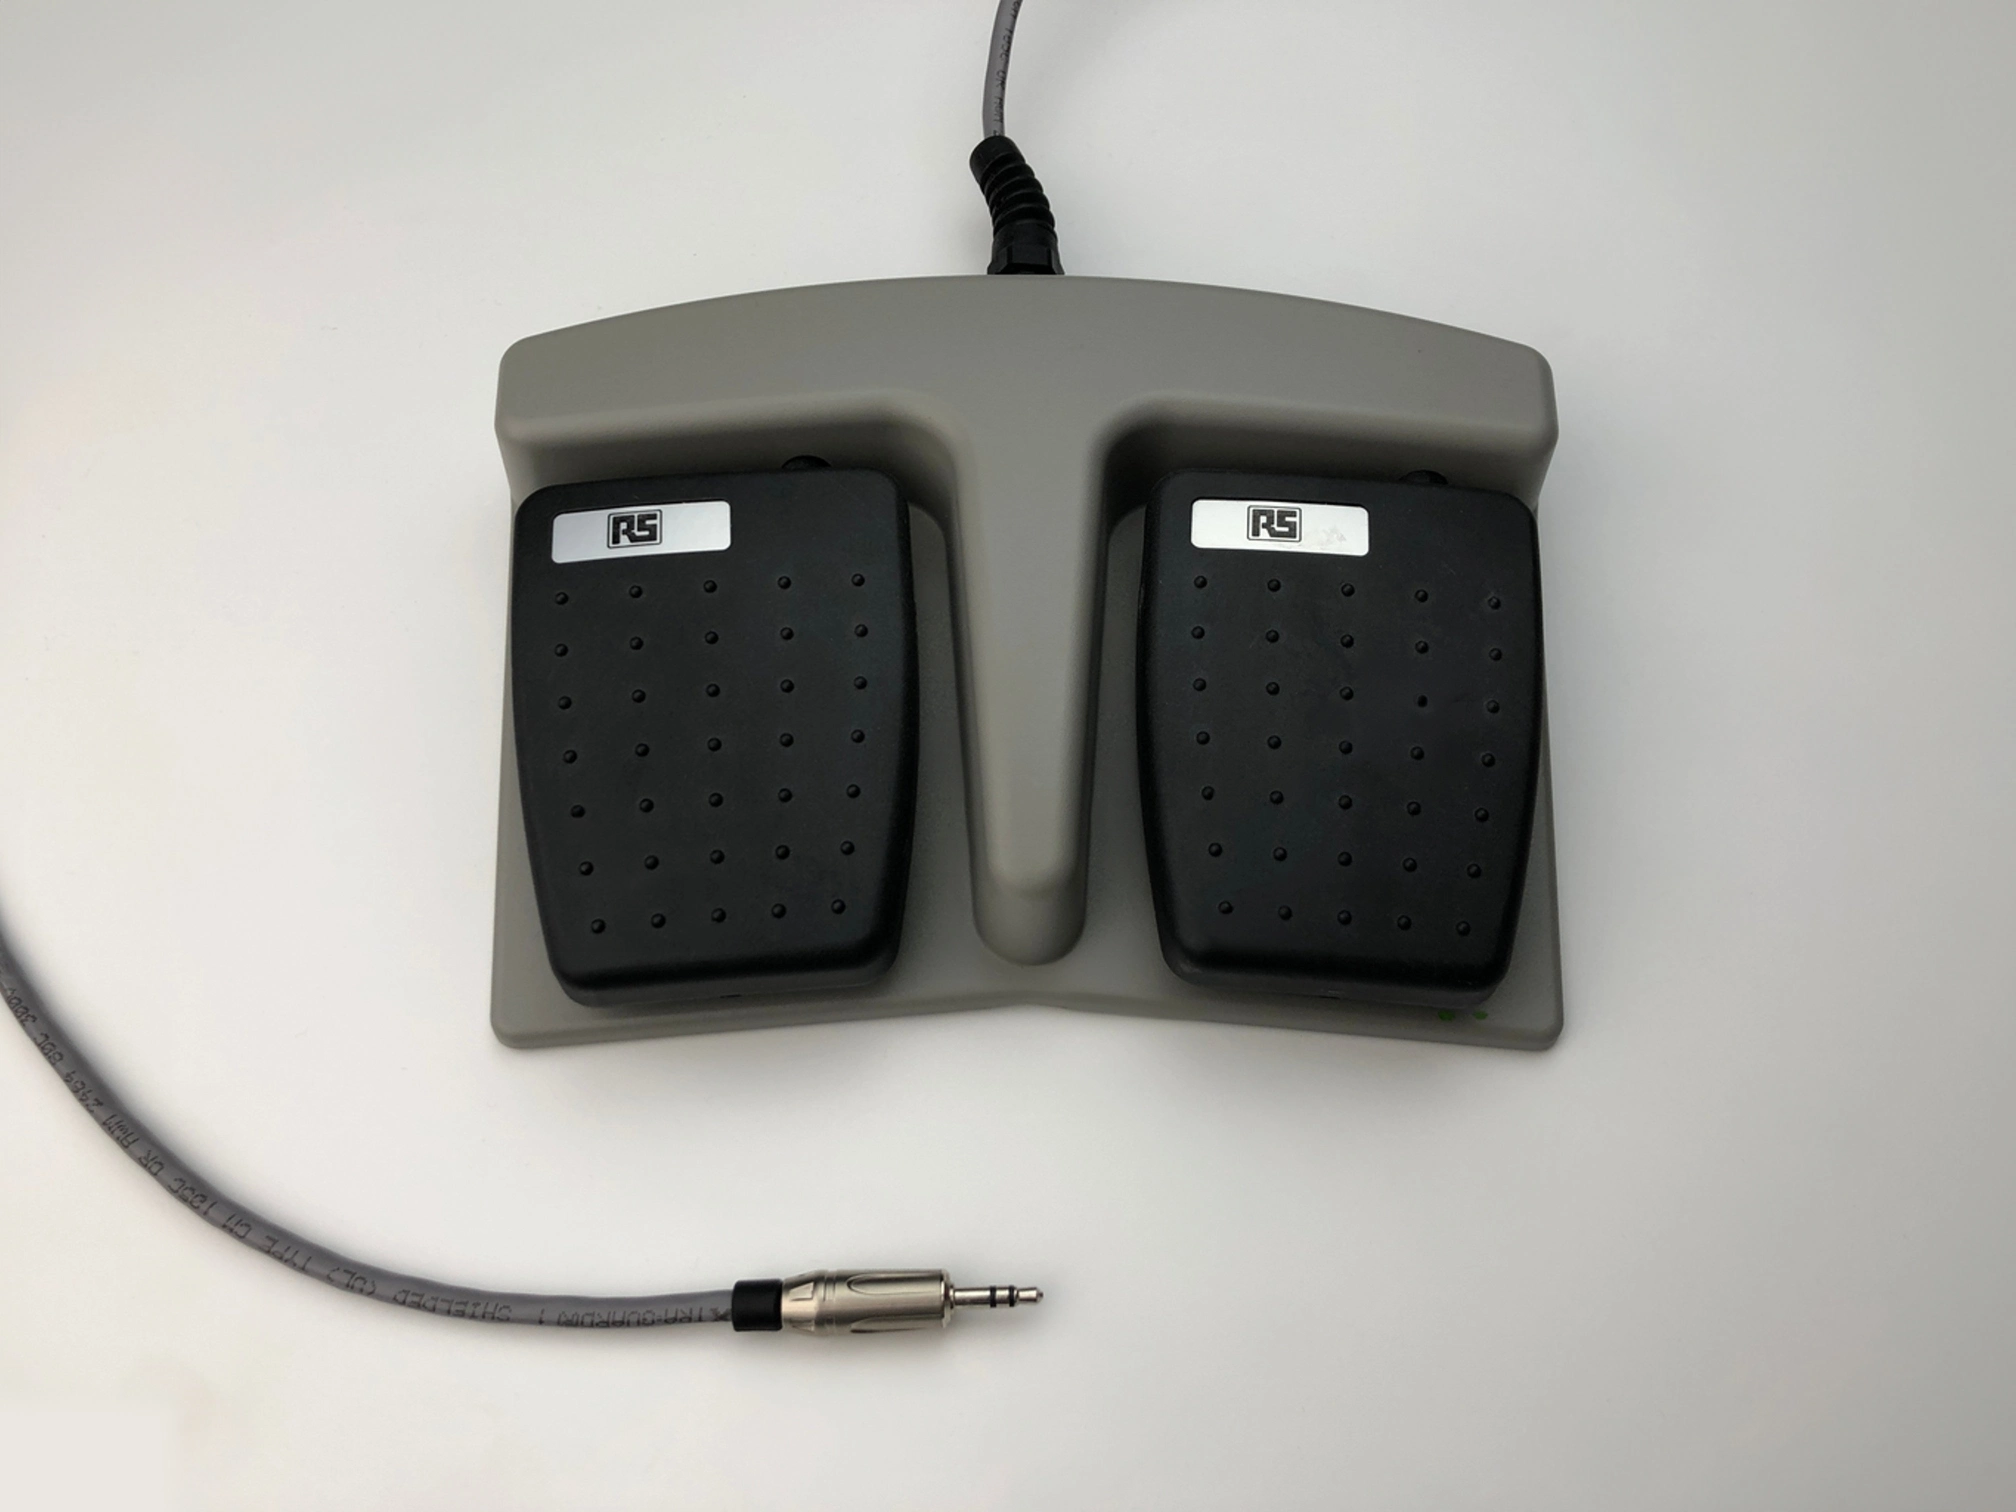
Double Footswitch Pedal
HA-ES-001
Data sheets
Avatar Port
4DOF haptic device for laparoscopic VR simulation
Avatar Instruments
Instrument handles, shafts and scope for Haptic Avatar
Avatar Trocar
4DOF tracking device for laparoscopic VR simulation
Questions or a quote?
Contact us Address
Ekvatorsvägen 8, 423 38 Torslanda, Sweden
© Follou AB. All rights reserved.
www.follou-haptics.com