T-RHEX
Twin haptic workstation for micro‑surgery
Features
6DOF
Tracking per hand
3DOF
Force feedback, X, Y, Z
150mm
Workspace cube per handpiece
0.09°
Orientation resolution
4µm
Position resolution
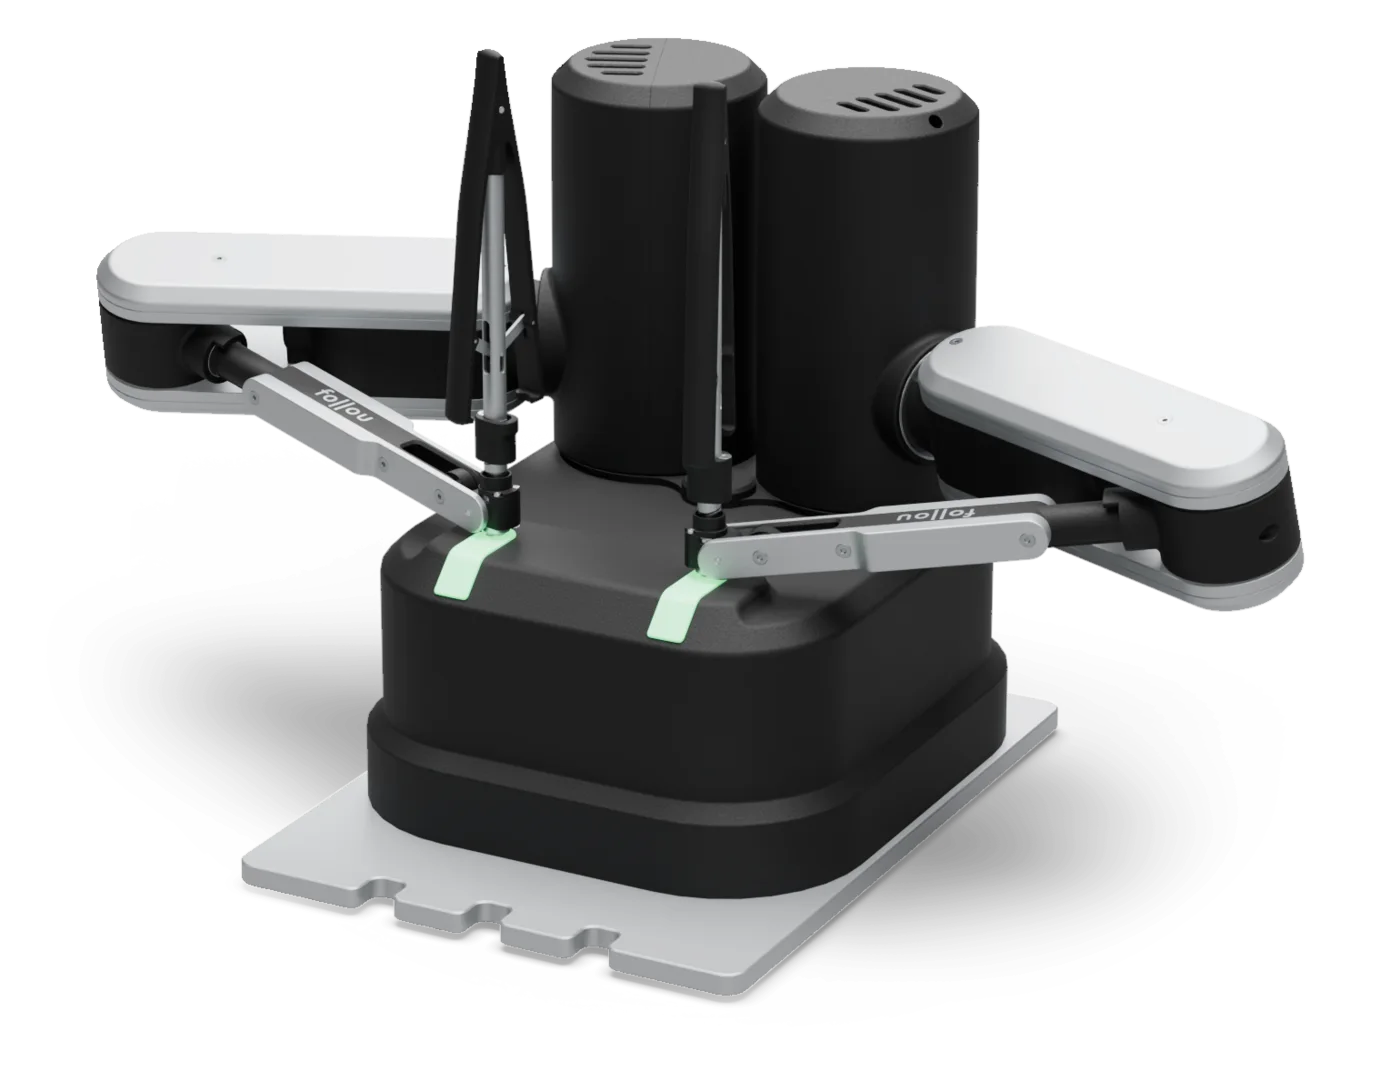
- Ergonomics and handling optimized for ophthalmic VR training, robotic surgery and general micro‑surgery.
- Brushless motors with incremental encoders for strength and durability.
- Simple and robust handpiece sensing, with no cable or Bluetooth.
- Parking positions with status LEDs and a magnetic zone that guides the tool pin home.
- Lightweight and compact, designed for robustness and simple maintenance.
Configurations
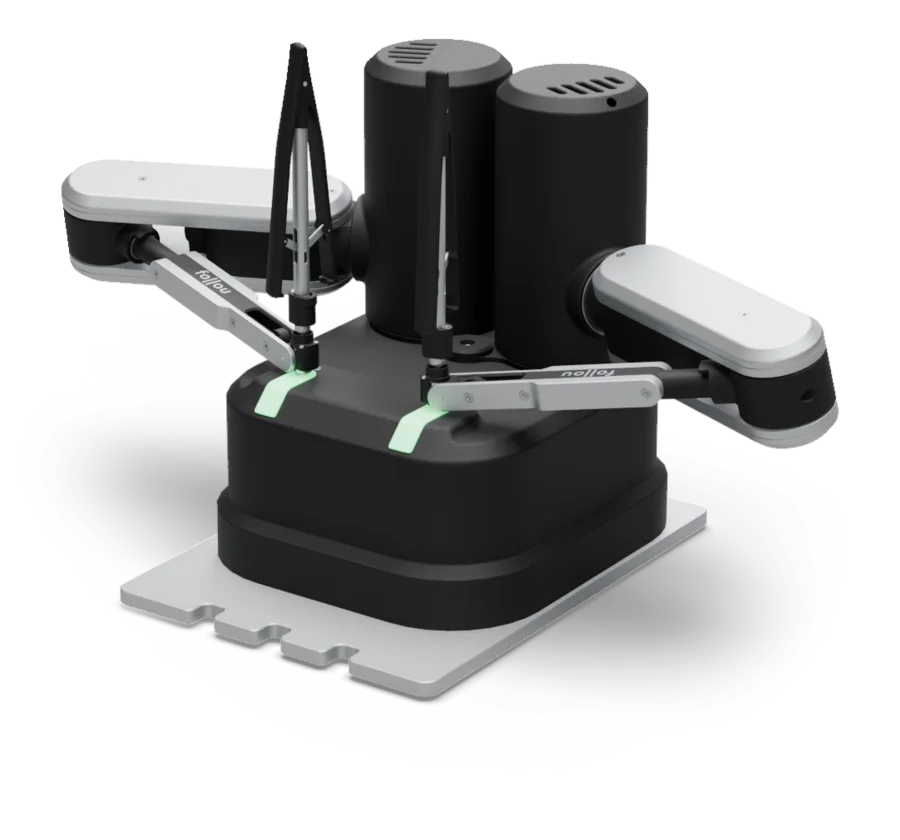
The haptic unit ready for training at a monitor, with handpieces in the parking positions.
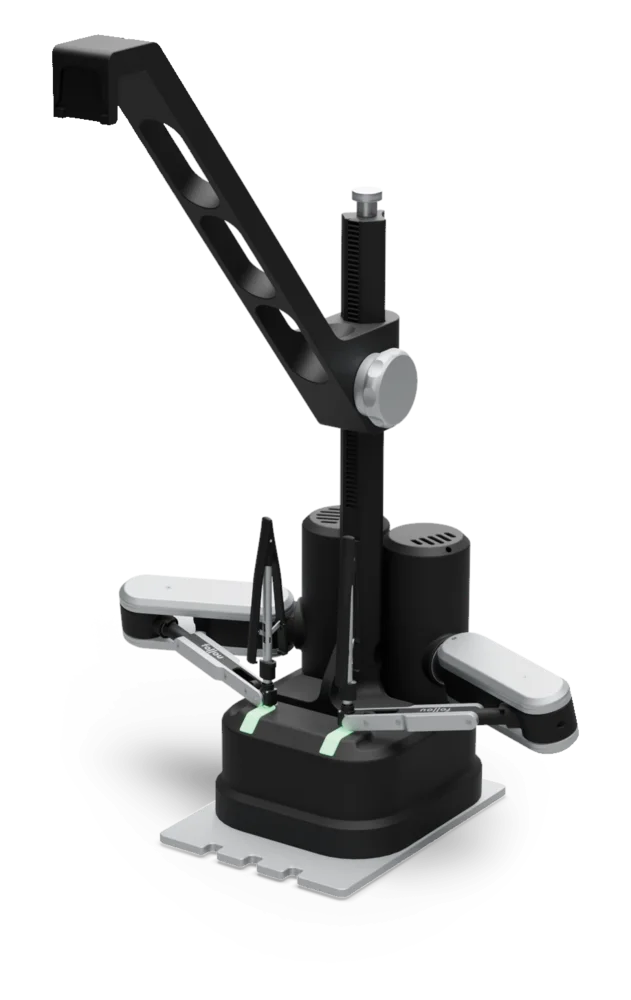
With the optional VR headset arm: a post and an adjustable arm hold the headset over the unit during head-mounted training.
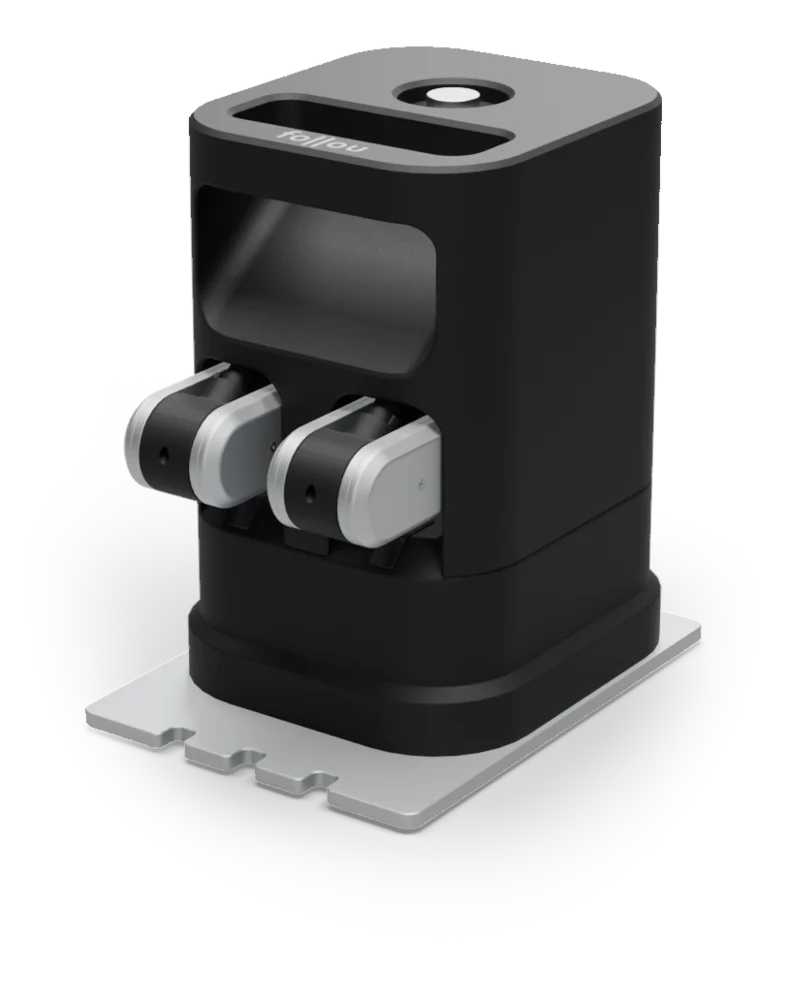
For transport, the arms fold up and the cover protects the arms and the tool pins.
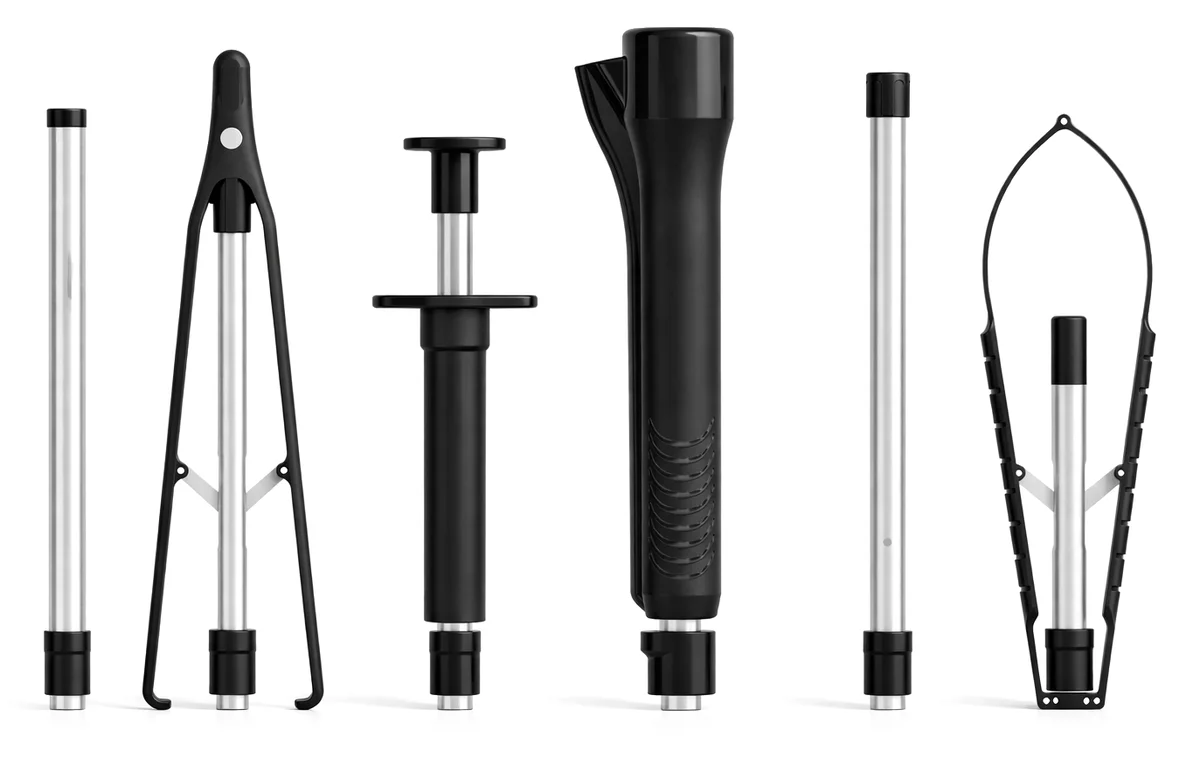
Handpieces
The delivered set holds a straight handpiece (e.g. a blade), forceps, a syringe, an IOL injector and a phaco handpiece. Other handpieces, such as scissors, on request.
Ready in 1 minute
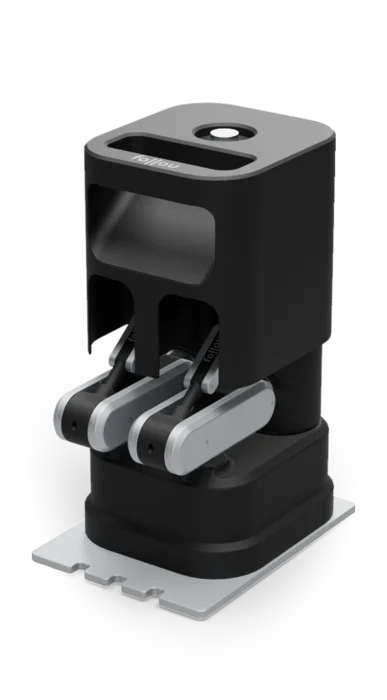
1Unpack
Lift off the protection cover and move the tool pins from the transport to the parking positions.
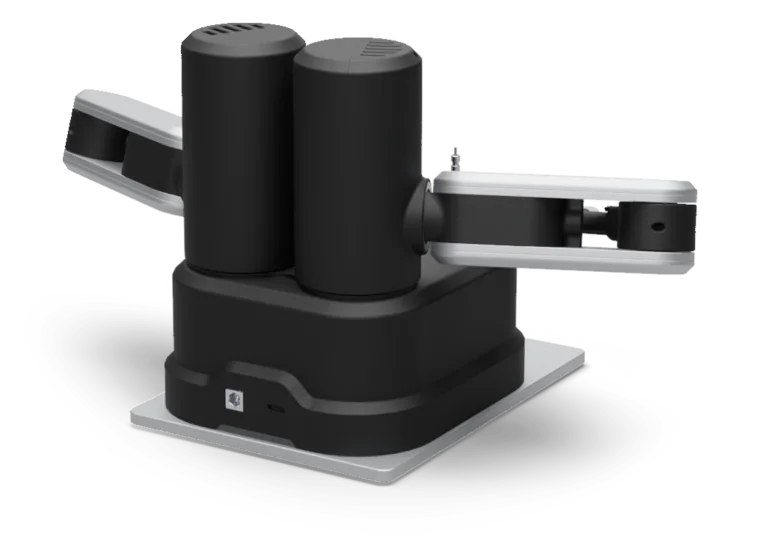
2Connect
Connect the 24 V power supply and the USB cable to the back of the unit, in any order.
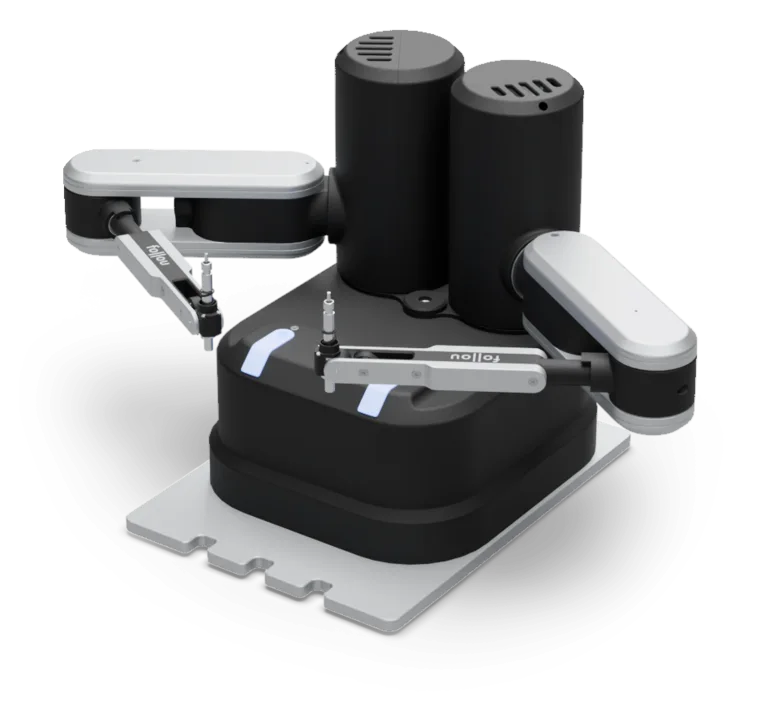
3Calibrate
Lift the tool pins about 2 cm, pull them about 5 cm towards you and park them. The LEDs turn from red to blue to green.
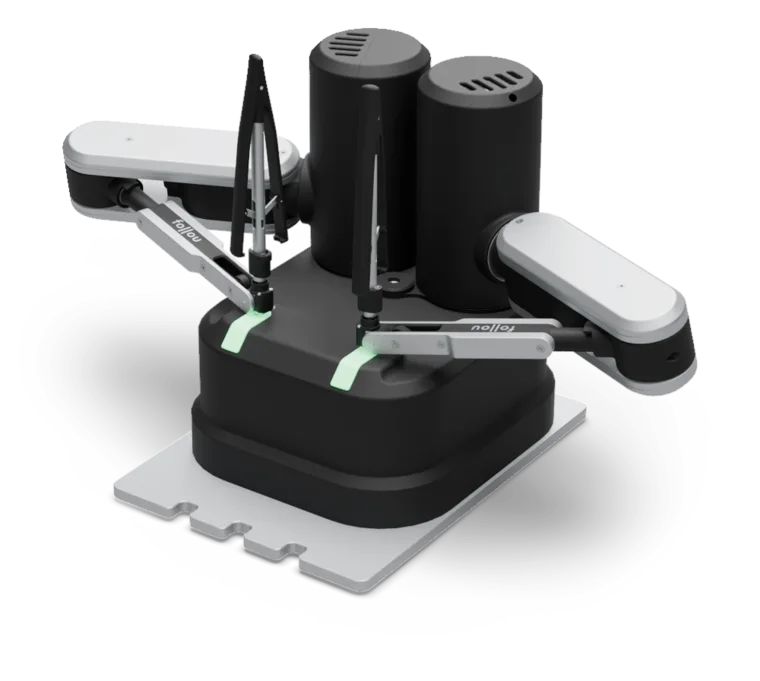
4Train
Start your simulation and click a handpiece onto each tool pin. A magnetic zone guides the pins home to park.
Integration
Follou's device library connects the T-RHEX to your simulation, whatever language it is written in.
Your simulation
Unity, C++, Python, a physics framework or any other environment
From Follou
Follou device library
A DLL on Windows, dylib on macOS, .so on Linux
T-RHEX
Left and right device: position, orientation and handpiece action. One USB cable; an internal hub connects both.
The library finds both devices, and your simulation reads positions, orientations and handpiece actions and sets forces, at over 6000 Hz for both devices. Interfaces are available for Unity, C++ and Python and for physics frameworks such as SOFA, DefKit, CHAI3D and iMSTK.
Specifications
Haptics performance, per device
| Peak force | 5.0 N | X, Y and Z. Limited when a motor winding reaches its maximum operating temperature. |
|---|---|---|
| Min force in free air | 0.05 N | Resistance from motors, transmissions and joint friction. |
| Max rendered stiffness | 1500 N/m | Based on testing. |
| Position resolution | 4 µm | X, Y and Z, in the neutral position (Arm1 and Arm2 at 90°). |
| Orientation resolution | 0.09° | Yaw, pitch and roll. |
| Translational workspace | 150 × 150 × 150 mm | A box for each handpiece; the two overlap about 100 mm in X. |
| Rotational workspace | Roll continuous Pitch −80° to +65° Yaw −125° to +125° | Roll around the tool axis without limit. Pitch front to back, yaw side to side. |
| Apparent mass | 10, 90, 40 g | X, Y and Z: the inertia of the arms and gimbals. |
| Gravity compensation | 10 g (programmable) | The largest imbalance, from Arm2 and Gimbal3. |
| Minimum distance | ~10 mm | Between the handpieces, when oriented similarly. |
| Max update frequency | >6000 Hz | For both devices. |
| Update latency | 35 µs | Total update time in the physics thread. |
The unit
| Devices | Two, left and right | In a common base, 62 mm apart (centre to centre). |
|---|---|---|
| Motors and sensors | 3 motors, 7 sensors per device | Brushless motors with incremental encoders for X, Y, Z; angle sensors for yaw, pitch, roll; one sensor for handpiece actions. |
| Communication | USB-C to USB-A | One cable to the computer. An internal hub connects each device with USB 2.0 high speed. |
| Power | 24 V / 300 W | External supply with a 5.5 × 2.5 × 11 mm barrel plug; EU and North American cords included. USB powers the controllers, the supply the motors. |
| Computer | Windows, macOS or Linux | 64-bit. One USB 2.0 or 3.0 port. |
| Handpieces | Five in the set | Straight (e.g. blade), forceps, syringe, IOL injector and phaco; others on request. 5 to 24 g each. |
| Accessories | Hand rests, case | Hand rests for temporal position (left/right) and superior positions (left and right); a handpiece case that splits in two. |
| Protection | Motor temperature | Output is limited at a 110 °C winding temperature; a fan cools automatically. |
| Environment | 10 to 30 °C | 20 to 80 % RH, non-condensing. Storage 0 to 40 °C. |
| Weight | 3.0 kg | Excluding power supply, cables, handpieces and accessories. |
Data sheet
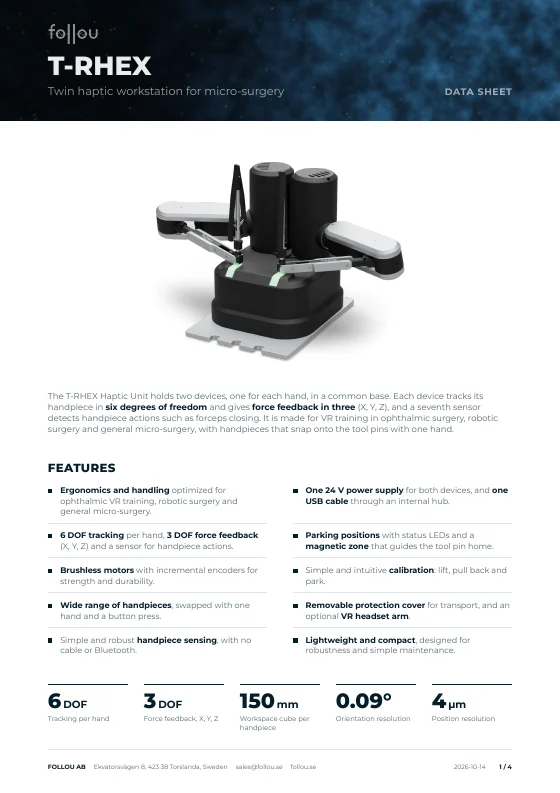
T-RHEX
Twin haptic workstation for micro‑surgery
Questions or a quote?
Contact us Address
Ekvatorsvägen 8, 423 38 Torslanda, Sweden
© Follou AB. All rights reserved.
www.follou-haptics.com